


DriveDNA: A Large-Scale Multimodal Naturalistic Driving Dataset and Benchmark for Driving Style Identification
Paper • 2607.23822 • Published • 2
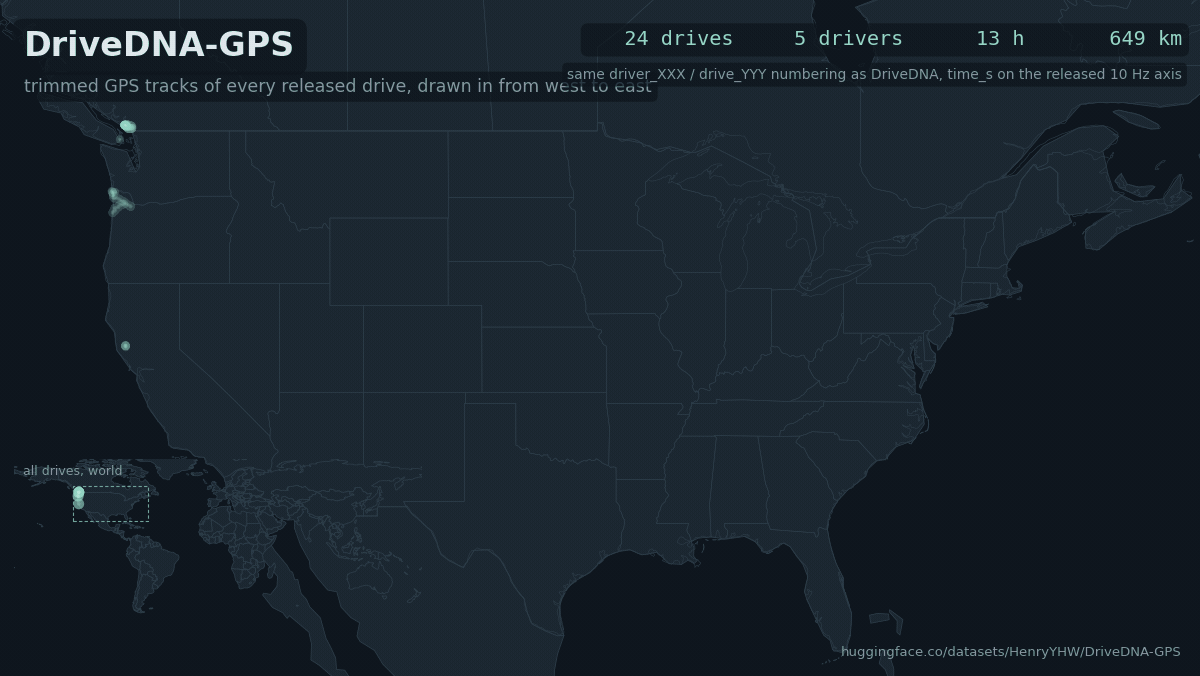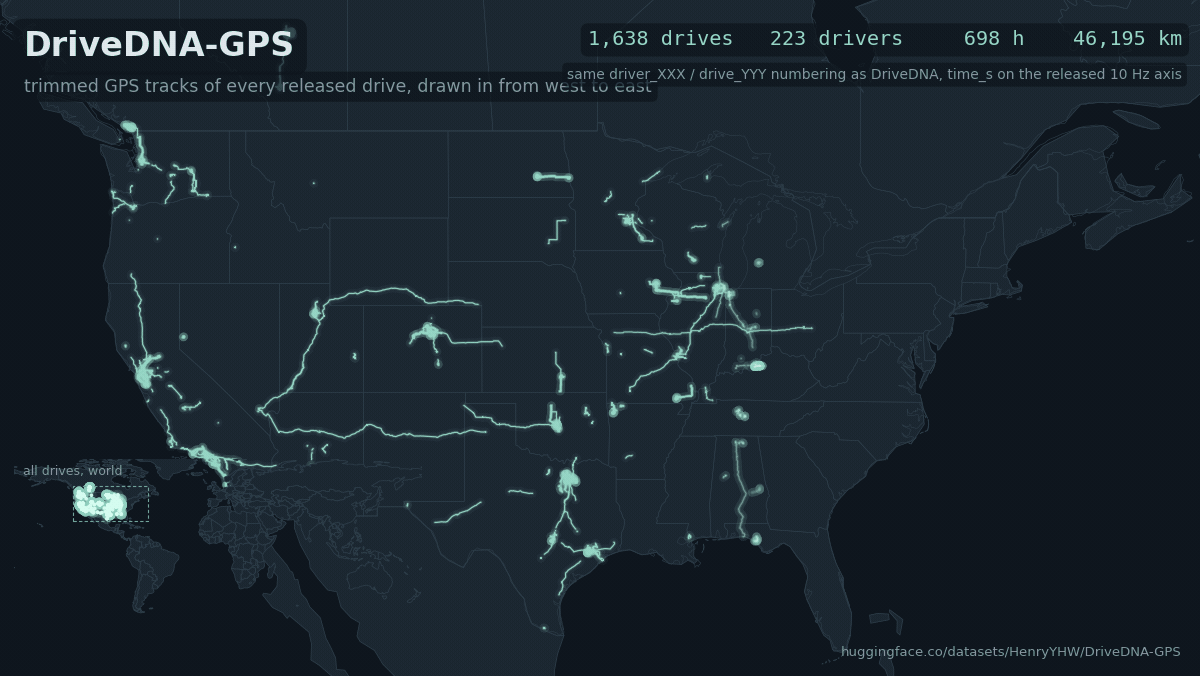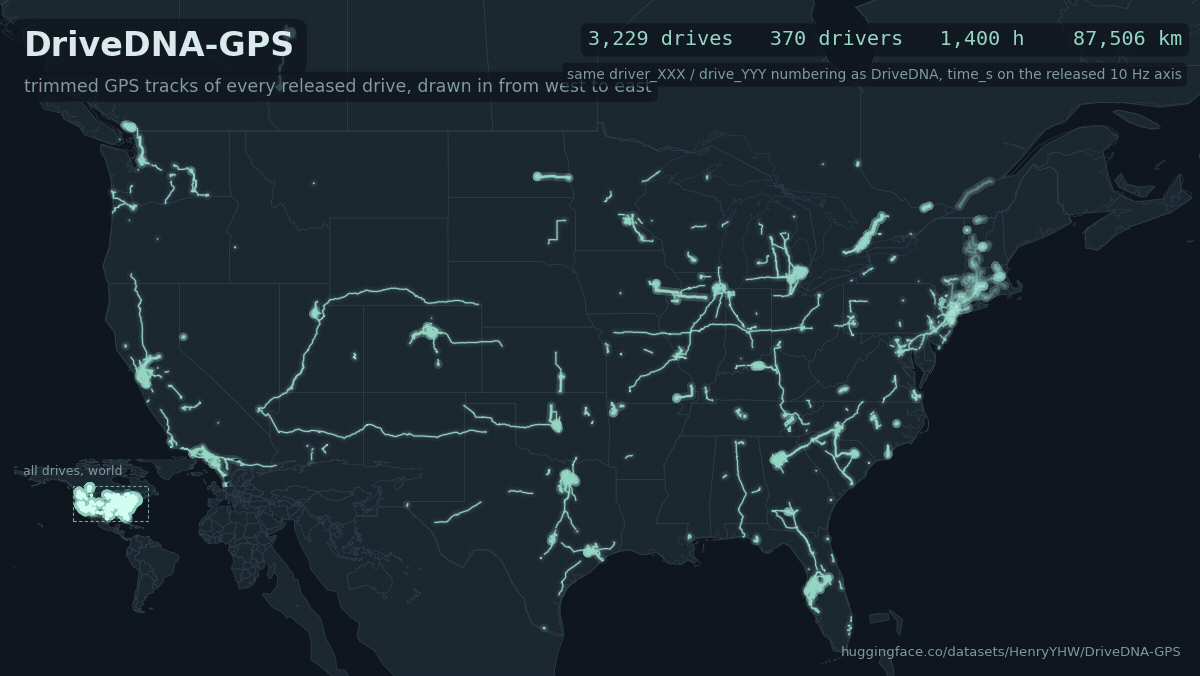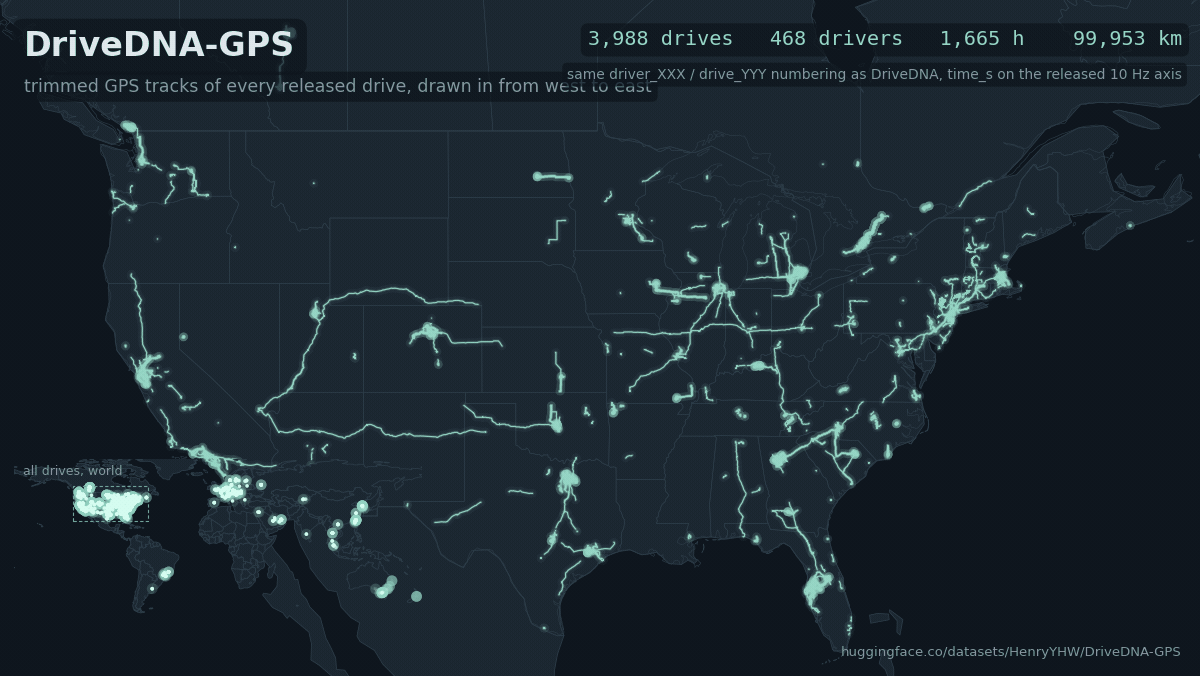
3,988 drives, 468 drivers, 1,665 hours of trimmed GPS track. Every drive keeps the pseudonym it has in the DriveDNA release.
driver_XXX/drive_YYY.csv), plus the openpilot localizer position (drive_YYY_kalman.csv) and raw GNSS position solutions (drive_YYY_gnss.csv) where the source logs carry them.driver_XXX/drive_YYY and time_s are identical to raw_signals/driver_XXX/drive_YYY.parquet in DriveDNA and DriveDNA-Controlled. A GPS row joins the released 10 Hz signals by time_s alone.120 <= time_s <= duration_s - 120). Drives shorter than four minutes have no file.time_s counts from the start of the released drive; the DriveDNA index gives the month.manifest.csv carries the evidence (align_frac, align_cov, n_seg_*).log column of every row says which log the row came from.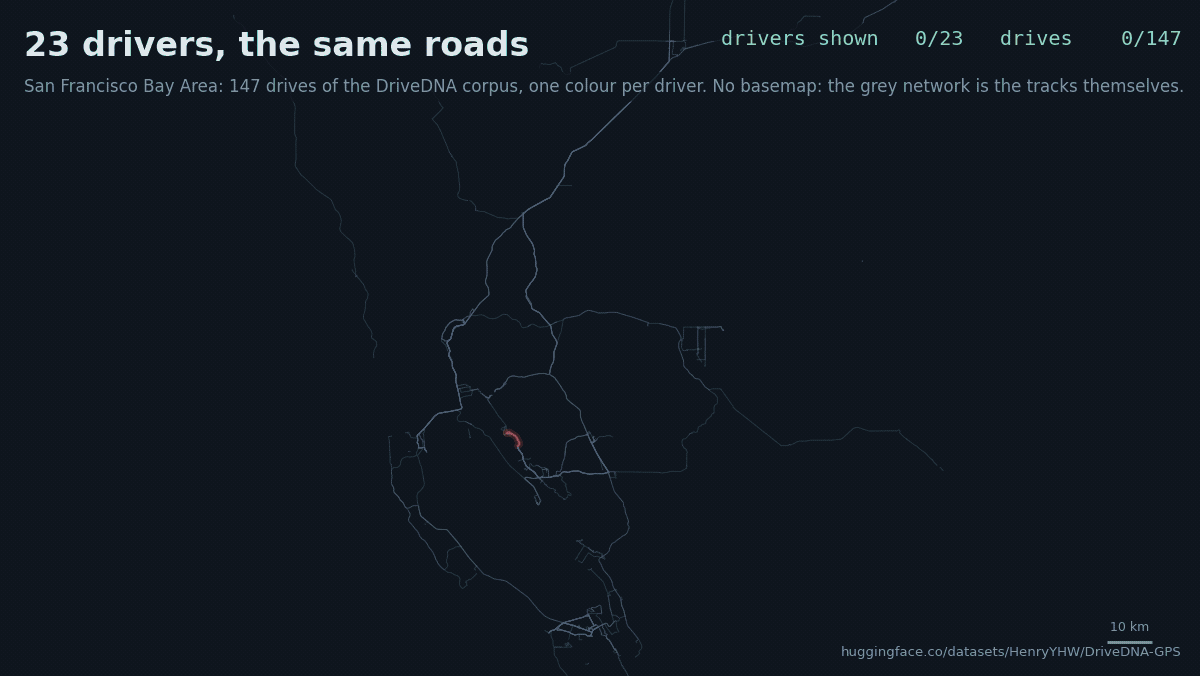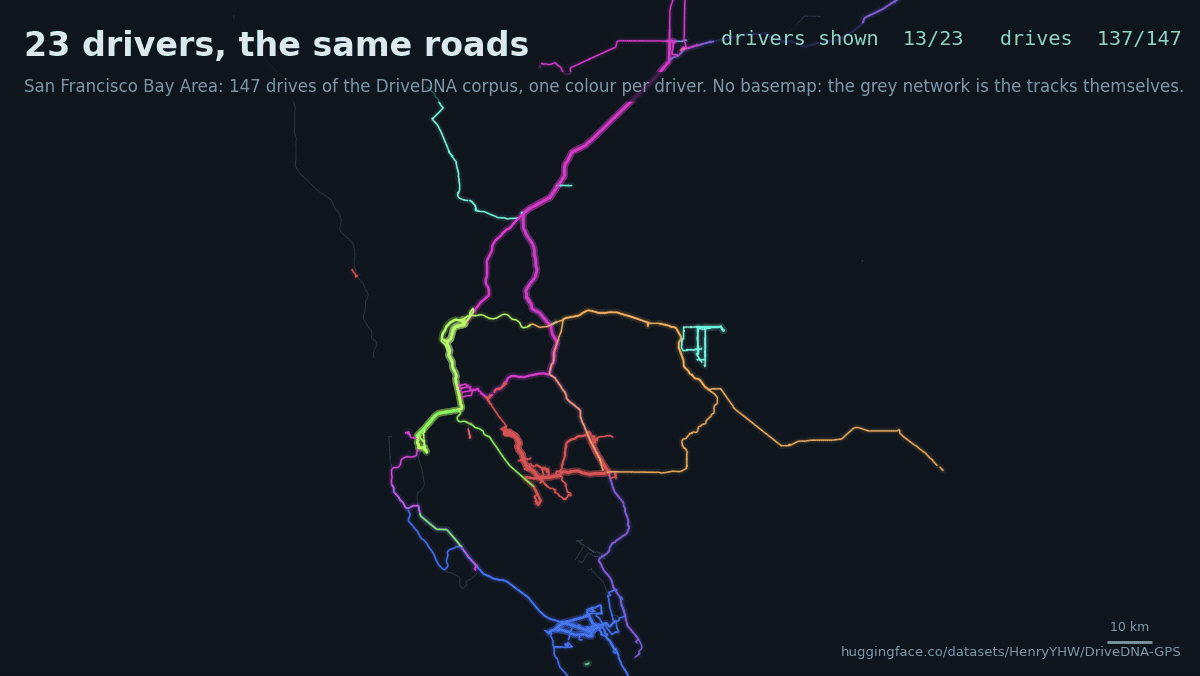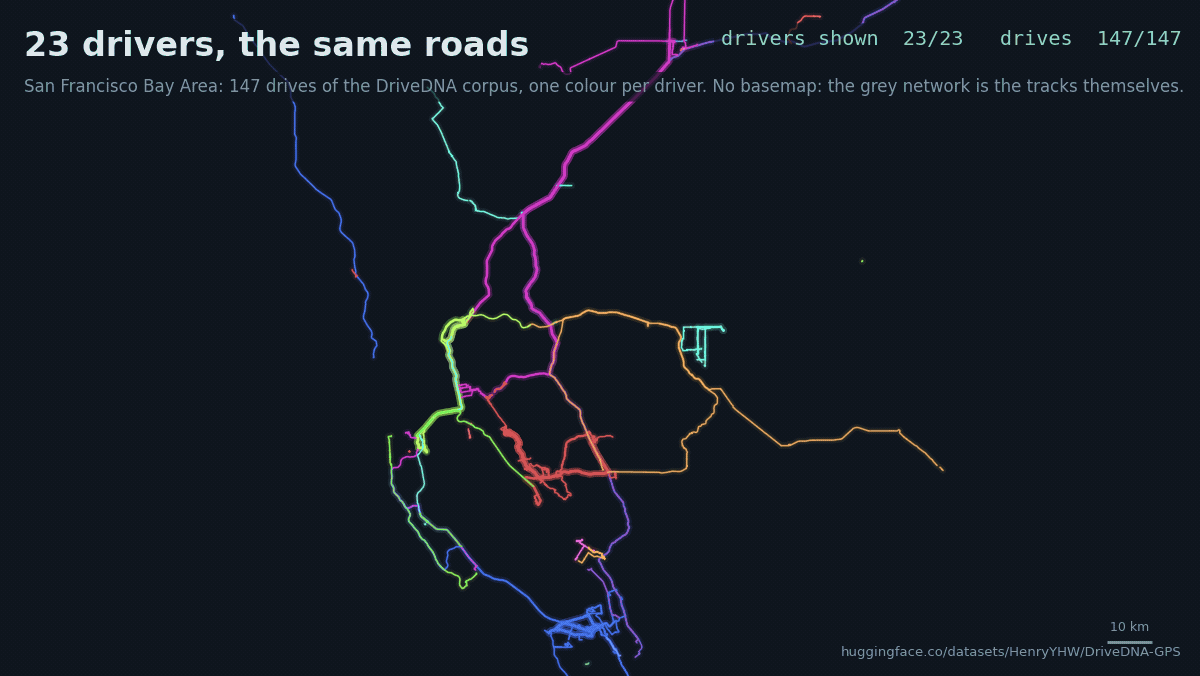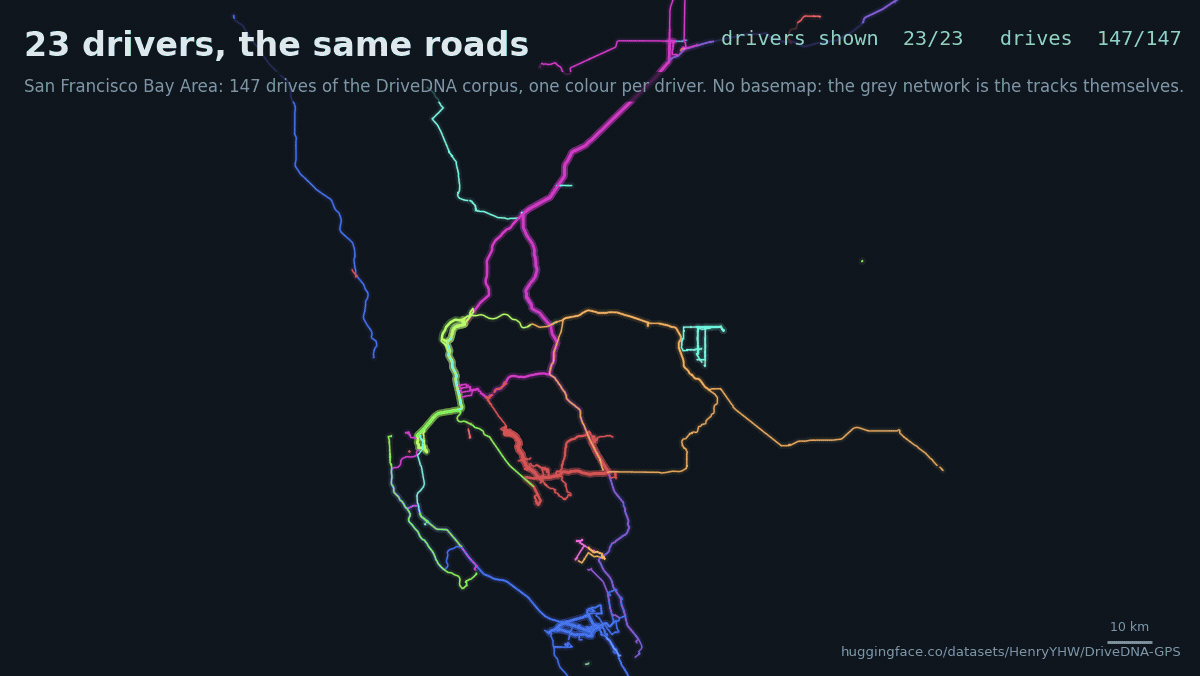
One road network, many drivers. The 147 drives of the 23 DriveDNA drivers in the San Francisco Bay Area are drawn one driver at a time, each in its own colour, over the grey network formed by all of their tracks. No basemap is used anywhere on this card: the roads are the tracks themselves.
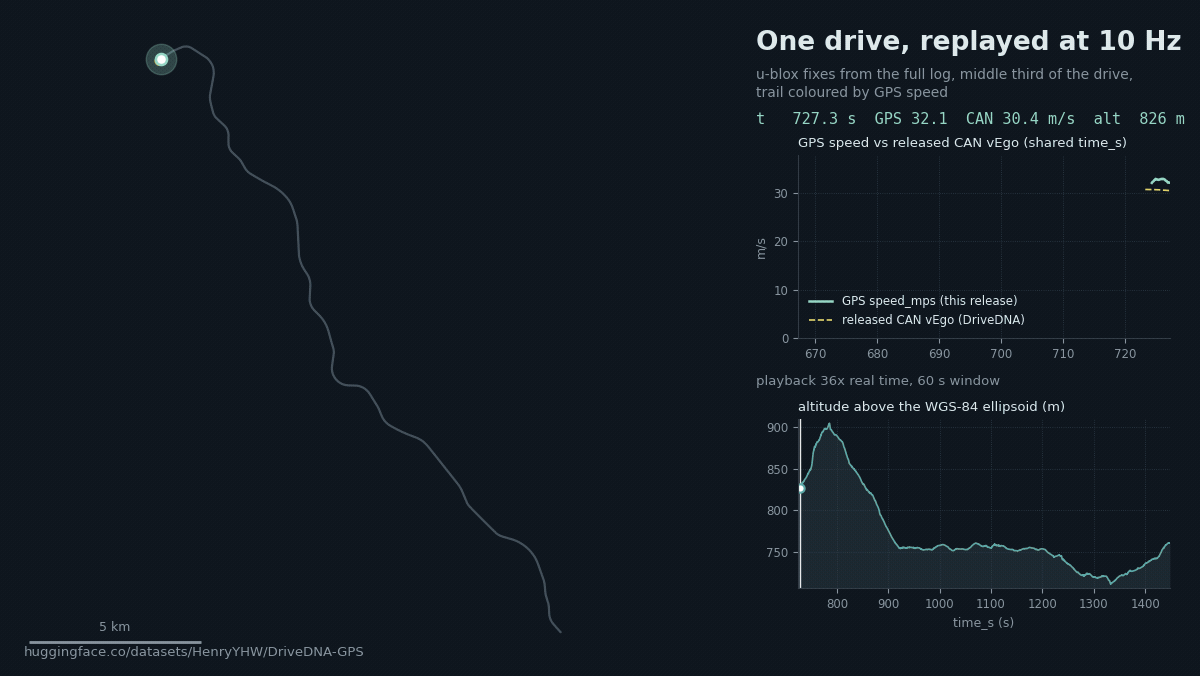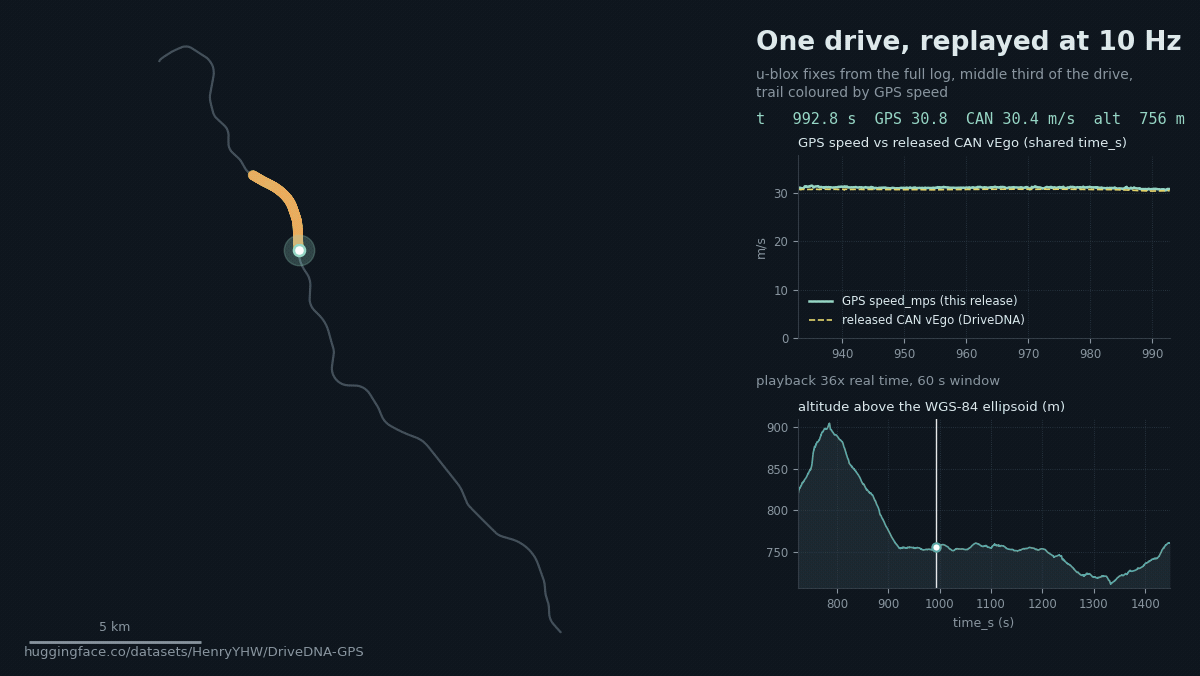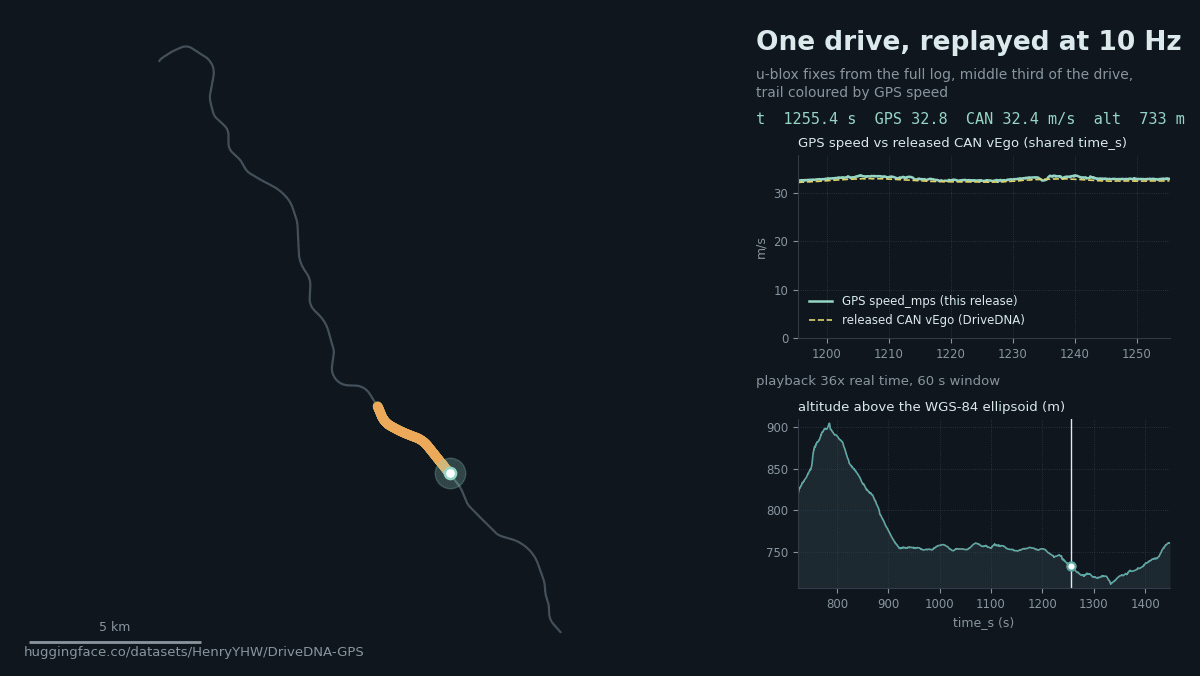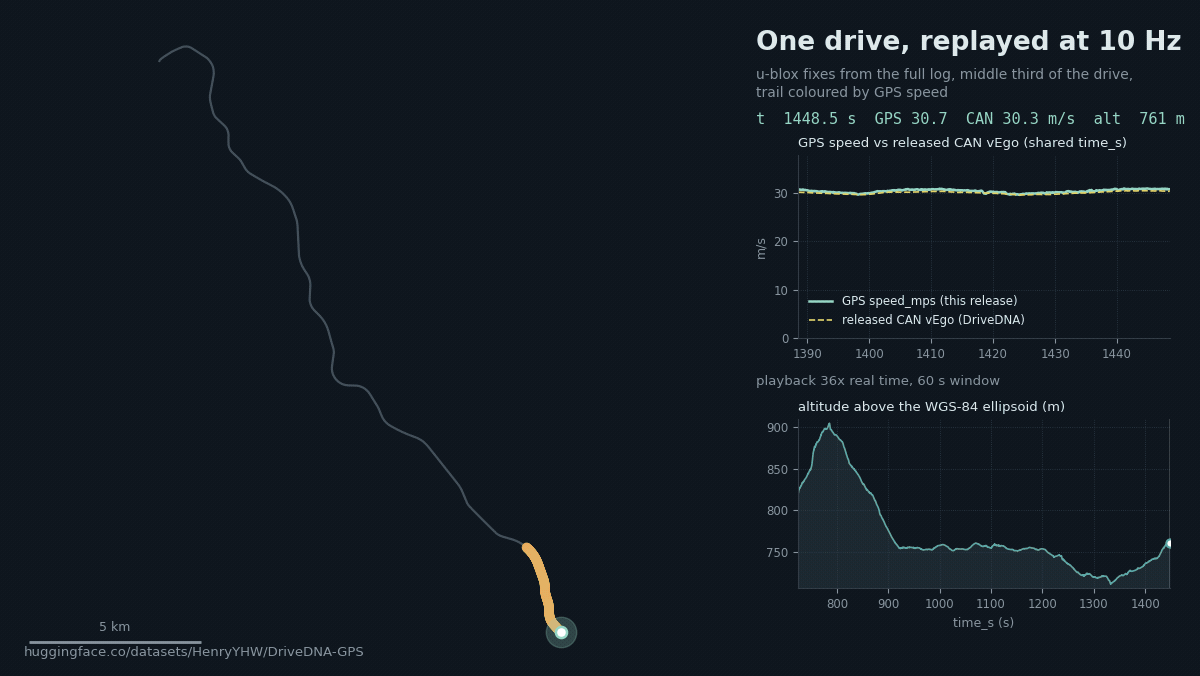
One drive at 10 Hz. The middle third of a drive replayed: the trail is coloured by GPS ground speed, the upper right panel overlays GPS speed_mps from this release with the CAN vEgo of the same drive from the DriveDNA release on the shared time_s axis, and the lower panel is the altitude profile.
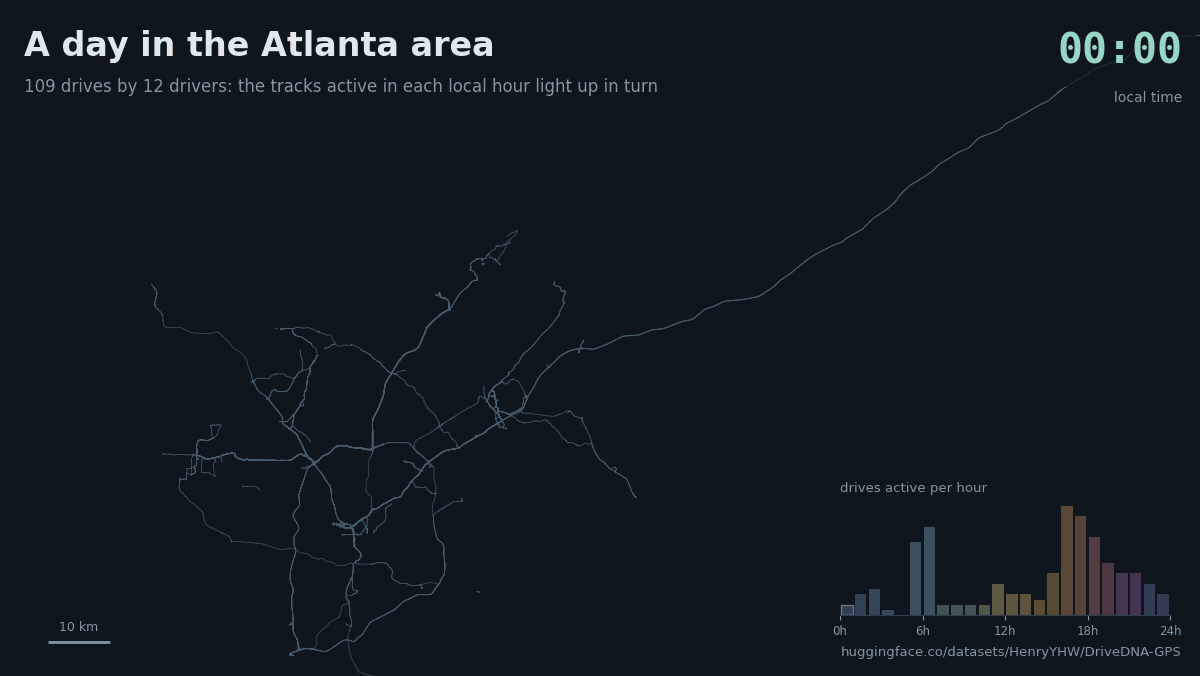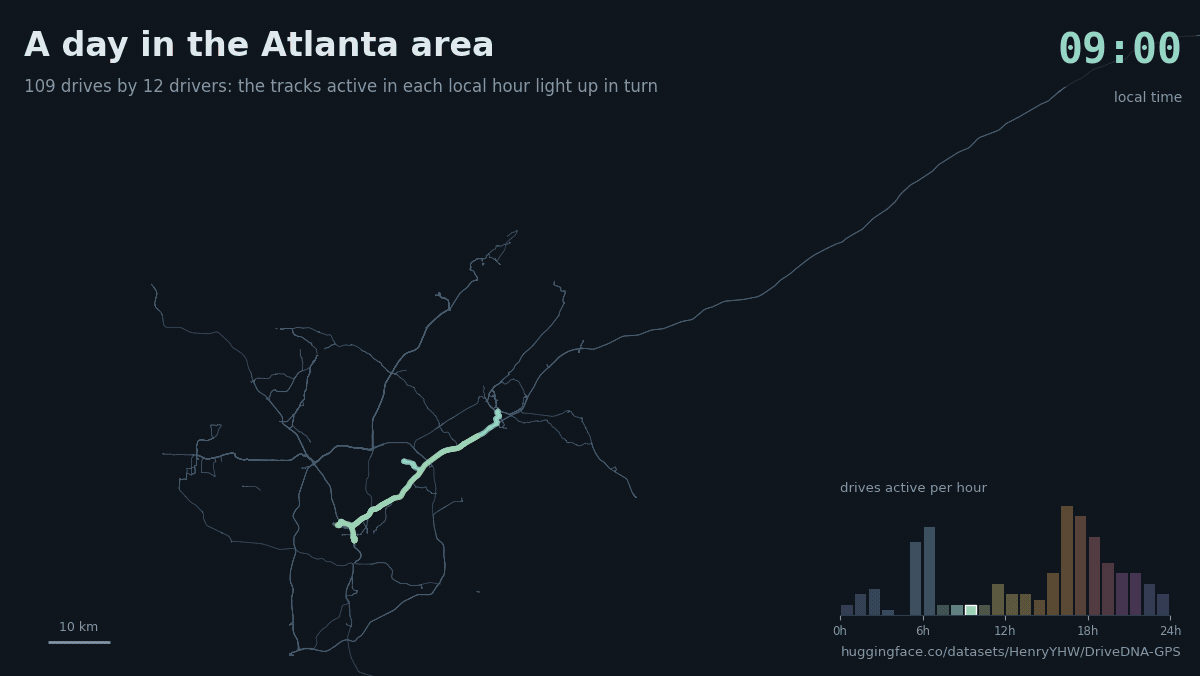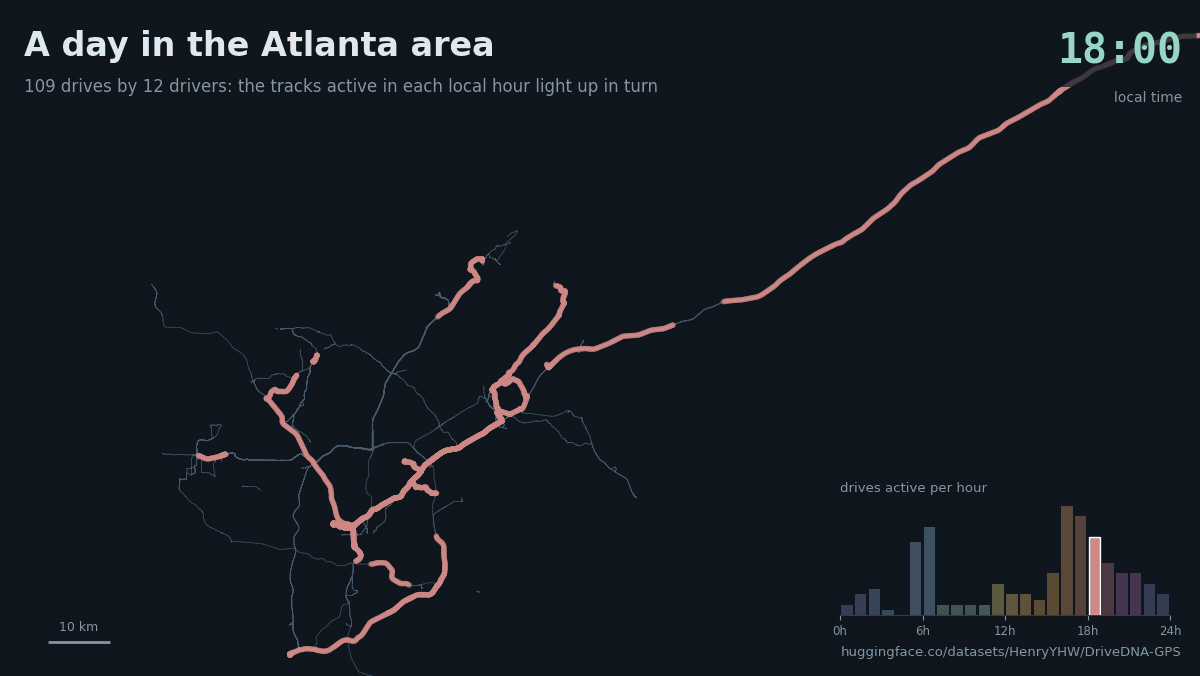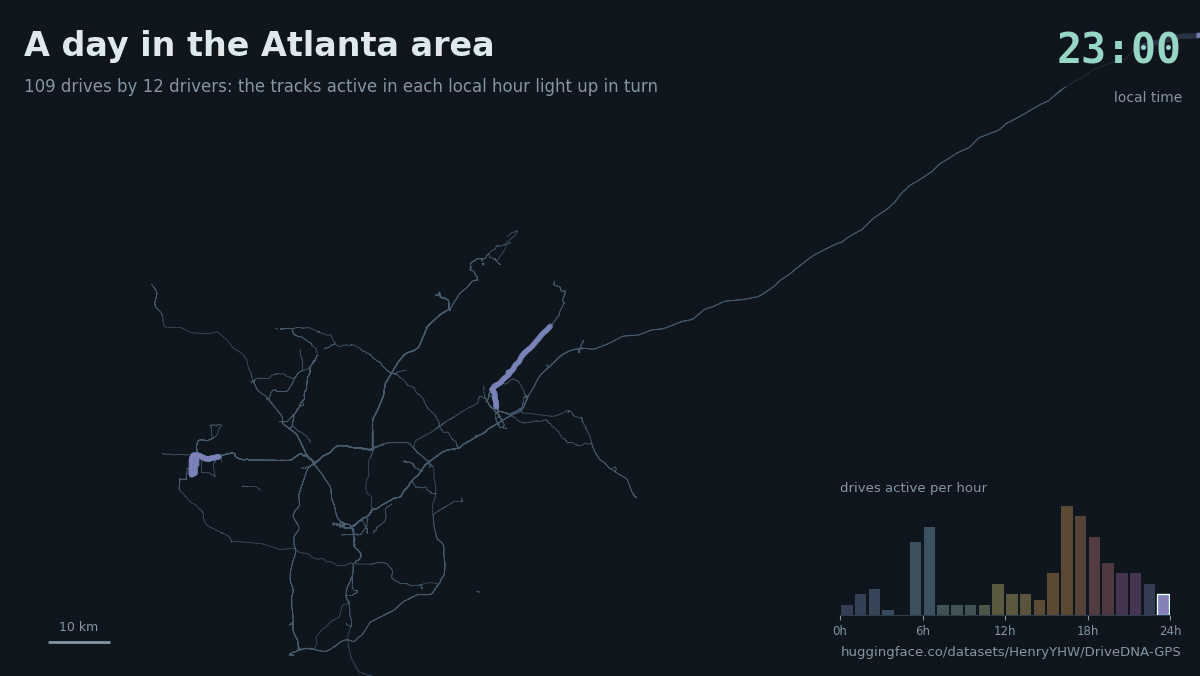
A day of driving. In the Atlanta area (109 drives by 12 drivers) the tracks active in each local hour light up in turn. The local hours were derived from private timestamps that are not part of the release.
| kind | files | rows | size | rate | source |
|---|---|---|---|---|---|
GPS fixes drive_YYY.csv |
3,994 | 12,090,649 (11,914,137 pass fix_ok) |
1.33 GB | 10 Hz or about 1 Hz | gpsLocationExternal (u-blox) and gpsLocation (Qualcomm modem, phone GPS on the oldest hardware) |
Localizer drive_YYY_kalman.csv |
1,615 | 34,372,875 (33,594,099 pass pos_ok) |
2.77 GB | 20 Hz or 4 Hz | liveLocationKalman.positionGeodetic, logs of openpilot 0.9.7 and older |
GNSS solutions drive_YYY_gnss.csv |
192 | 3,304,542 | 364 MB | about 1 Hz | gnssMeasurements position and Kalman ECEF solutions, logs from 2022 to 2023 |
manifest.csv |
1 | 4,177 | 1 MB | one row per DriveDNA drive, including the drives that have no file |
5,801 CSV files, 4.46 GB in total. Of the 3,988 drives with a usable GPS track, 995 were logged by a u-blox receiver and 2,998 by a Qualcomm modem receiver; 432 tracks are at 10 Hz and 3,556 at about 1 Hz.
driver_001 to driver_460 are the DriveDNA corpus (4,121 drives). driver_461 to driver_474 are the 56 drives of DriveDNA-Controlled (14 participants, one Honda Civic, the same road network).time_s is the axis of the released 10 Hz table of the same drive: 0.0 is its first row and duration_s in the manifest is its last time_s. GPS rows carry time_s with millisecond resolution, so join with merge_asof (tolerance 0.05 s) or round to the 10 Hz grid.too_short, 103 drives), logs without any GPS message (no_gps_msgs), receivers that never obtained a fix (no_valid_fix; a file with only fix_ok = 0 rows is still written when any non-zero coordinate falls inside the window), fixes only inside the trimmed minutes (no_fix_in_window), and 4 drives whose time axis could not be verified (align_failed). The manifest lists every drive with its status.DriveDNA-GPS/
├── README.md
├── manifest.csv one row per DriveDNA drive
├── driver_001/
│ ├── drive_001.csv GPS fixes
│ ├── drive_001_kalman.csv localizer position, when the logs carry it
│ ├── drive_001_gnss.csv raw GNSS position solutions, when the logs carry them
│ └── ...
├── driver_002/
└── ... driver_474/
drive_YYY.csv (GPS fixes)
One row per GPS message. Rows with (0, 0) coordinates were dropped; every other message is kept, so filter on fix_ok == 1 (or your own rule) before use. Numbers are rounded: time_s to 3 decimals, coordinates to 7 decimals (about 1 cm), metres to 2 decimals, speeds to 3 decimals.
| column | meaning |
|---|---|
time_s |
seconds on the released drive axis |
msg |
gpsLocationExternal: position from the external u-blox receiver. gpsLocation: position from the internal receiver (Qualcomm modem GNSS, or the phone GPS of the oldest hardware) |
source |
receiver as logged: ublox, qcomdiag, android (rare) |
log |
rlog (full log; u-blox at 10 Hz) or qlog (decimated log; about 1 Hz) the row was read from. A drive can switch between the two from one minute to the next |
seg |
one-minute segment index of the drive's log, as counted by openpilot. The released time_s does not necessarily start at segment 0 |
latitude, longitude |
WGS-84 degrees |
altitude_m |
height above the WGS-84 ellipsoid in metres, not above sea level; values around 0 or below near the coast are normal |
speed_mps |
ground speed from the receiver, m/s (Doppler based, independent of the CAN speed) |
bearing_deg |
course over ground, degrees clockwise from true north, 0 to 360; meaningless when stationary |
h_acc_m |
estimated horizontal position accuracy, metres (u-blox typically 1 to 3 m; qcomdiag always 0, the modem does not report it) |
v_acc_m |
u-blox: estimated vertical accuracy, metres. qcomdiag: a vertical dilution value from the modem, typically 1 to 2, exactly 500 when there is no fix |
speed_acc_mps |
estimated speed accuracy, m/s |
bearing_acc_deg |
estimated course accuracy, degrees; tens of degrees when stationary or slow |
flags |
receiver flags as logged. For u-blox this is the NAV-PVT flags byte (bit 0 = fix OK); for qcomdiag it is 0 or 1 and does not indicate validity |
has_fix |
the hasFix field as logged. It is False in every log from openpilot 0.9.7 and older even for good fixes, so do not filter on it alone |
fix_ok |
1 if the row passes the per-source validity rule below; the recommended filter |
drive_YYY_kalman.csv (openpilot localizer, older logs only)
| column | meaning |
|---|---|
time_s, log, seg |
as above |
latitude, longitude, altitude_m |
liveLocationKalman.positionGeodetic (WGS-84, ellipsoid height) |
std_x, std_y, std_z |
reported standard deviation of the position estimate, metres |
vel_n, vel_e, vel_d |
velocity in the north, east, down frame, m/s |
status |
localizer status string (valid, uninitialized, ...) |
gps_ok, pos_valid |
the gpsOK flag and the positionGeodetic.valid flag |
pos_ok |
1 if gps_ok and pos_valid and status == "valid"; the recommended filter |
drive_YYY_gnss.csv (raw GNSS position solutions, logs from 2022 to 2023)
| column | meaning |
|---|---|
time_s, log, seg |
as above |
kind |
position: single-epoch position solution. kalman: the GNSS daemon's own filtered solution |
x, y, z |
ECEF coordinates, metres |
std_x, std_y, std_z |
reported standard deviation, metres |
valid |
the solution's valid flag |
latitude, longitude, altitude_m |
the same point converted to WGS-84 (ellipsoid height) |
manifest.csv
| column | meaning |
|---|---|
set, driver, drive |
main or controlled; pseudonyms |
status, reason |
ok, too_short, no_gps_msgs, no_valid_fix, no_fix_in_window or align_failed, with a short reason |
duration_s, trim_lo_s, trim_hi_s |
length of the released table and the kept window |
op_version |
openpilot version of the logs (numeric part) |
n_seg_read, n_seg_rlog, n_seg_qlog, log_policy |
one-minute segments read, by log type; qlog_fallback = the whole drive was read from decimated logs |
k_anchor, align_method, align_frac, align_cov, align_lag_s, anchor_frac |
time-axis verification, see below |
n_seg_hole, n_seg_qlog_retry, n_seg_bad, n_seg_misnamed, n_seg_moving_ok, seg_frac_min, n_pos_jumps |
per-segment verification, see below |
gps_file, gps_rows, gps_rows_ok, gps_msgs, gps_sources, gps_rate_hz, first_ok_s, last_ok_s, max_gap_s |
GPS file summary: rows, rows passing fix_ok, message types, receivers, median rate, first and last valid fix, largest gap between valid fixes |
lat_med, lon_med |
median position of the valid fixes |
kalman_file, kalman_rows, kalman_rows_ok, gnss_file, gnss_rows |
companion files |
fix_ok)
All sources: coordinates are not (0, 0) and within range. Then
ublox: has_fix is set or flags & 1 == 1, and h_acc_m < 100000, and the receiver timestamp was after 2016 (the module emits stale positions and 2015 dates before its first fix);qcomdiag: has_fix is set or 0 < v_acc_m < 500 (the rule of openpilot's own GPS daemon);android and others: has_fix is set or 0 < h_acc_m < 100.Known limitation: after a warm start a u-blox module may repeat its last stored position for a few seconds with the fix flag set. Those rows look valid; comparing speed_mps with the released vEgo exposes them.
vEgo: align_frac is the share of 10 Hz samples within 0.1 m/s, align_cov the share of the released span covered by the logs, align_method how the anchor was found (k_min: the decode-time first segment, 3,655 drives; k_min_alt: the first segment according to the decimated logs, 218; seg_scan: a scan over segment starts, 48). 67 drives in which the vehicle never moves, or whose released speed is constant, cannot be checked this way; they keep the decode's own anchor and carry _unverifiable in align_method.n_seg_qlog_retry, 906 segments) and dropped when that did not match either (n_seg_bad, 919 segments); 21 drives were read entirely from decimated logs. Files whose timestamps do not fit their segment index are detected the same way (n_seg_misnamed, 242 drives). Segments in which the released speed is linear or constant for most of the minute (n_seg_hole, 1,785 drives) cannot be checked there and are kept. seg_frac_min is the worst per-segment match among kept segments. n_pos_jumps counts pairs of consecutive valid fixes of one receiver, at most 10 s apart, that imply more than 100 m/s: 122 files have a non-zero count, nearly all from near-simultaneous 10 Hz messages a few metres apart; kilometre-scale jumps occur in two Qualcomm tracks whose gps_rate_hz is far below 1.120 <= time_s <= duration_s - 120. The trim is relative to the drive, not to the first or last fix; first_ok_s and last_ok_s in the manifest show where the valid track starts and ends inside the window.align_cov < 0.9: part of the released span is not covered by the log files available today, so their track has a gap or ends early.| set | ok | too_short | no_gps_msgs | no_valid_fix | no_fix_in_window | align_failed | total |
|---|---|---|---|---|---|---|---|
| main | 3,940 | 96 | 58 | 11 | 12 | 4 | 4,121 |
| controlled | 48 | 7 | 1 | 0 | 0 | 0 | 56 |
| all | 3,988 | 103 | 59 | 11 | 12 | 4 | 4,177 |
log column); resample before computing accelerations or headings from positions.h_acc_m and speed_acc_mps help to weight them.pip install -U huggingface_hub pandas pyarrow
hf download HenryYHW/DriveDNA-GPS --repo-type dataset --local-dir DriveDNA-GPS # whole set, 4.46 GB
from huggingface_hub import hf_hub_download
import pandas as pd

REPO = "HenryYHW/DriveDNA-GPS"
gps = pd.read_csv(hf_hub_download(REPO, "driver_002/drive_001.csv", repo_type="dataset"))
gps = gps[gps["fix_ok"] == 1]

# join with the released 10 Hz signals of the same drive (DriveDNA, same pseudonyms, same time_s)
sig = pd.read_parquet(hf_hub_download("HenryYHW/DriveDNA", "raw_signals/driver_002/drive_001.parquet",
                                      repo_type="dataset"))
joined = pd.merge_asof(gps.sort_values("time_s"), sig.sort_values("time_s"),
                       on="time_s", direction="nearest", tolerance=0.05)
print(joined[["time_s", "latitude", "longitude", "speed_mps", "vEgo"]].head())
With 🤗 datasets: load_dataset("HenryYHW/DriveDNA-GPS", "gps") (configs gps, kalman, gnss, manifest).
Released under the DriveDNA research license; the terms are those of the main repository, HenryYHW/DriveDNA.
@article{drivedna2026,
  title   = {DriveDNA: A Large-Scale Multimodal Naturalistic Driving Dataset and
             Benchmark for Driving Style Identification},
  author  = {Wang, Yuhang and Li, Lingyao and Zhou, Hao},
  journal = {arXiv preprint arXiv:2607.23822},
  year    = {2026}
}
Please cite the DriveDNA paper and refer to this release as DriveDNA-GPS.