

LimX Oli
Collection
Models and tools for LimX Oli, the full-size general-purpose humanoid robot. • 1 item • Updated
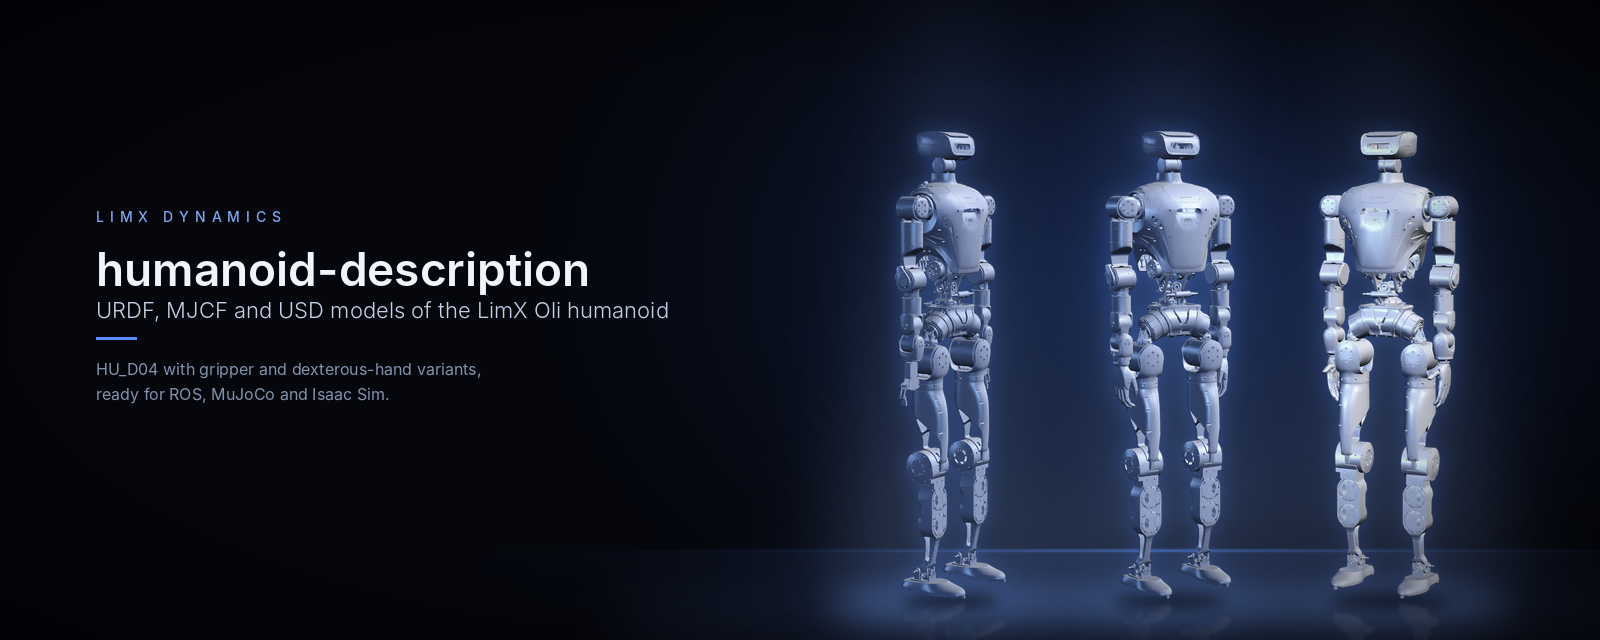
Reinforcement-learning policies in ONNX for the LimX Oli full-size humanoid (HU_D04_01, 31 joints), ready to run in MuJoCo or on the real robot with humanoid-rl-deploy-python.
These files are mirrored as-is from humanoid-rl-deploy-python. The GitHub repository is the source of truth.
| Controller | Remote buttons | Files |
|---|---|---|
| Walk | R1 + X | walk_controller/policy/default/policy.onnx, walk_controller/walk_param.yaml |
| Mimic (greeting motion) | L1 + B | mimic_controller/policy/default/policy.onnx, lin_encoder.onnx, priv_encoder.onnx, mimic_controller/mimic_param.yaml |
| Stand | L1 + Y | stand_controller/joint_params.yaml |
| Damping | L1 + A | damping_controller/joint_params.yaml |
HU_D04_01/controllers.yaml lists the controllers loaded by the deploy code.
Run on Linux x86_64 with humanoid-mujoco-sim and humanoid-rl-deploy-python in the same folder. The deploy repository already contains these policies.
pip install humanoid-mujoco-sim/limxsdk-lowlevel/python3/amd64/limxsdk-*.whl click
export ROBOT_TYPE=HU_D04_01
python humanoid-mujoco-sim/simulator.py            # terminal 1
python humanoid-rl-deploy-python/main.py           # terminal 2
humanoid-mujoco-sim/robot-joystick/robot-joystick  # terminal 3
To download the policies from here instead:
hf download limxdynamics/oli-rl-policies --local-dir ./oli-rl-policies
To deploy your own walking policy, replace walk_controller/policy/default/policy.onnx. See the deploy repository for details.
These policies drive a physical robot. Test in simulation first, run with a trained operator present, and keep the emergency stop within reach.
Apache 2.0, the same as humanoid-rl-deploy-python.