

tamago117/HaptoFlow
Updated
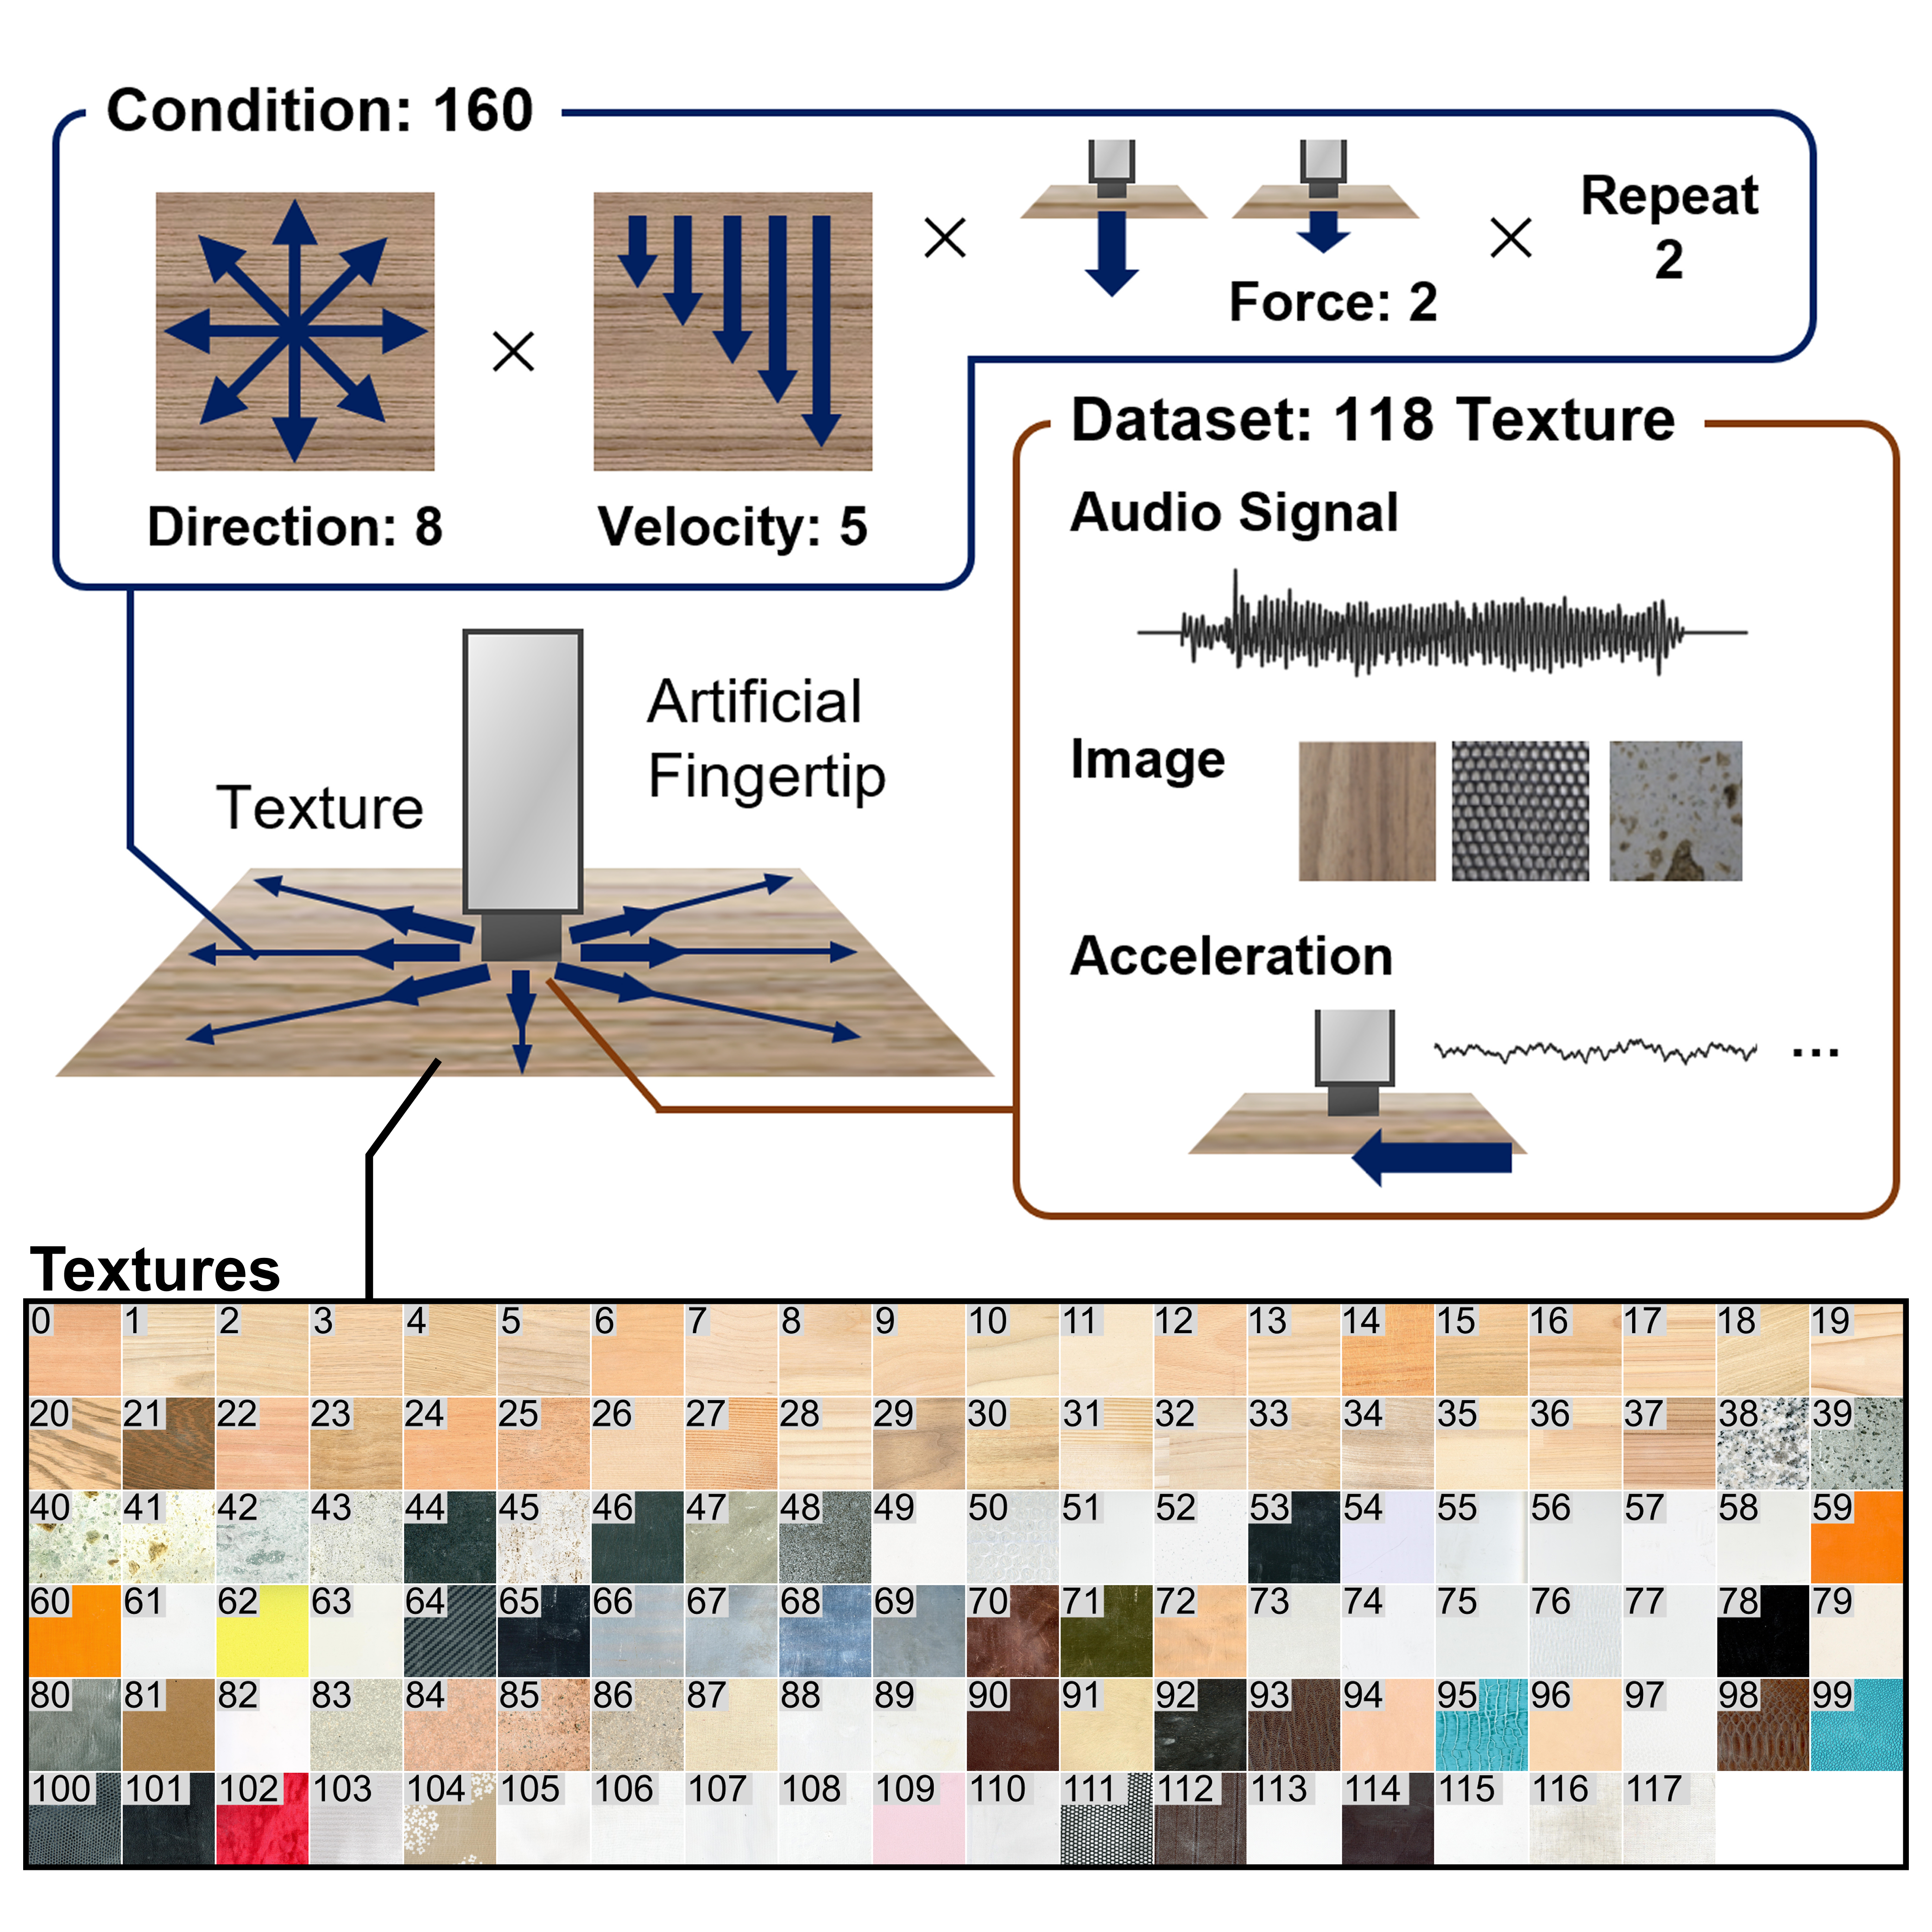
Sliding-contact recordings of 118 real material surfaces: contact sound, 3-axis acceleration, normal force and probe position, captured under a controlled sweep of scan direction, velocity and pressing force.
Want to render these textures in VR? HaptoFlow is a Flow Matching model trained on this dataset that generates vibrotactile feedback in real time. Check it out!
.
├── images/
│   ├── images_scan_area/   (images of the 100x100 mm scan area)
│   └── crop_images/        (for evaluation of texture classification)
├── sensor_data/
│   ├── audio/              (after noise cancelling)
│   ├── raw_audio/
│   ├── accel/
│   ├── force/
│   └── position/
├── texture_list.xlsx       (texture names and their friction coefficients)
└── README.md
img(texture_id).jpgimg0.jpg(texture_id)_(direction)_(velocity)_(force)_(repeat count).parquet or .flac
See texture_list.xlsx.
Clockwise angle (degree) — 0, 45, 90, 135, 180, 225, 270, 315.
Scan speed (mm/s) — 20, 30, 40, 50, 60.
Push force (mN) — 500 or 1000.
Number of scan — 0 or 1.
0_135_40_500_0.parquet
Sound source after noise cancelling.
Raw sound source.
time_ns (int64, nanoseconds)X, Y, Z (float32, g)time_ns X Y Z
999053 0.014 0.067 -0.960
1209053 0.034 0.048 -0.946
1339053 0.029 0.062 -0.952
time_ns (int64, nanoseconds)force (float32, N)time_ns force
999053 1.009
1209053 1.009
1339053 1.009
time_ns (int64, nanoseconds)X, Y (float32, mm)time_ns X Y
613000 0.0 45.0
10477000 0.0 45.0
19940000 0.0 45.0
import pandas as pd

df = pd.read_parquet("sensor_data/accel/0/0_135_40_500_0.parquet")
df.insert(0, "time", df.pop("time_ns") / 1e9)   # seconds
@misc{eguchi2025clusterhaptictexturedataset,
      title={Cluster Haptic Texture Dataset: Haptic Texture Dataset with Varied Velocity-Direction Sliding Contacts},
      author={Michikuni Eguchi and Tomohiro Hayase and Yuichi Hiroi and Takefumi Hiraki},
      year={2025},
      eprint={2407.16206},
      archivePrefix={arXiv},
      primaryClass={cs.HC},
      url={https://arxiv.org/abs/2407.16206},
}

@inproceedings{eguchi2025whc_wip,
  title={Cluster Haptic Texture Database: Haptic Texture Database with Controlled Sliding-Contact Interactions},
  author={Michikuni Eguchi and Yuichi Hiroi and Tomohiro Hayase and Takefumi Hiraki},
  booktitle={2025 IEEE World Haptics Conference Work in Progress (WHC WiP)},
  year={2025},
  organization={IEEE}
}