

Magic-W0: A Structured World–Action Foundation Model for Physical Intelligence
Magic-Lab Team · Magiclab Robotics Inc.
Abstract
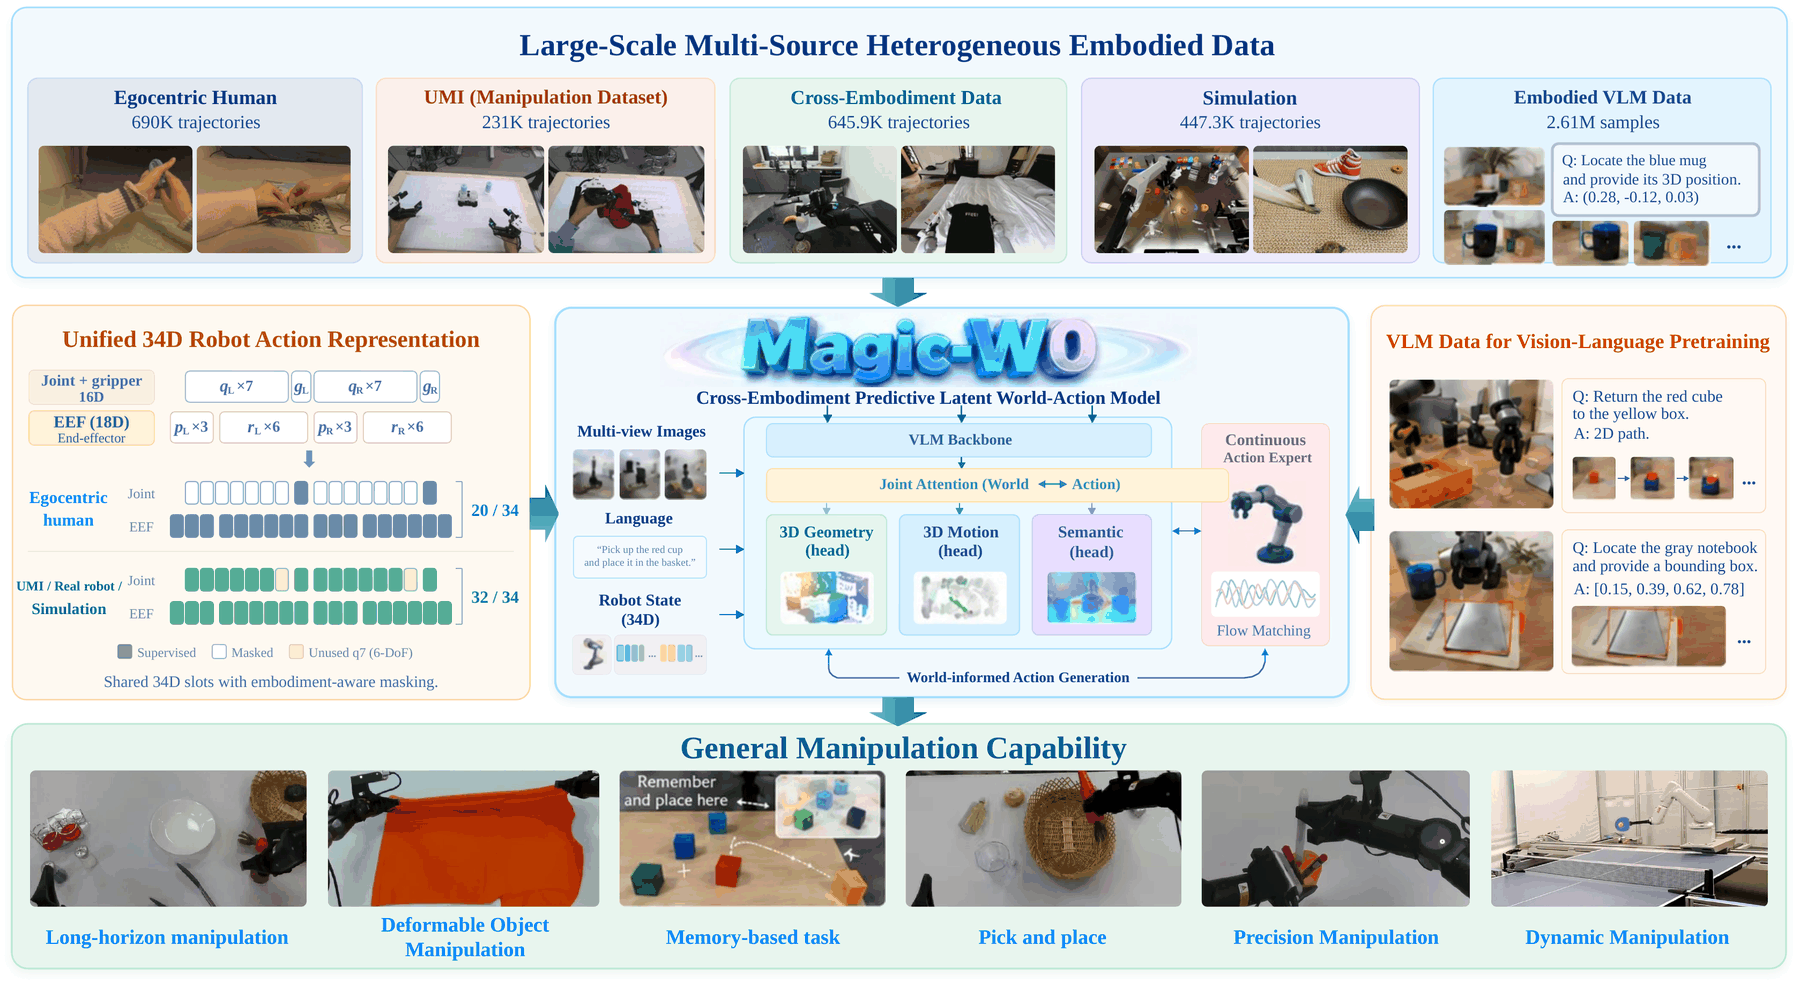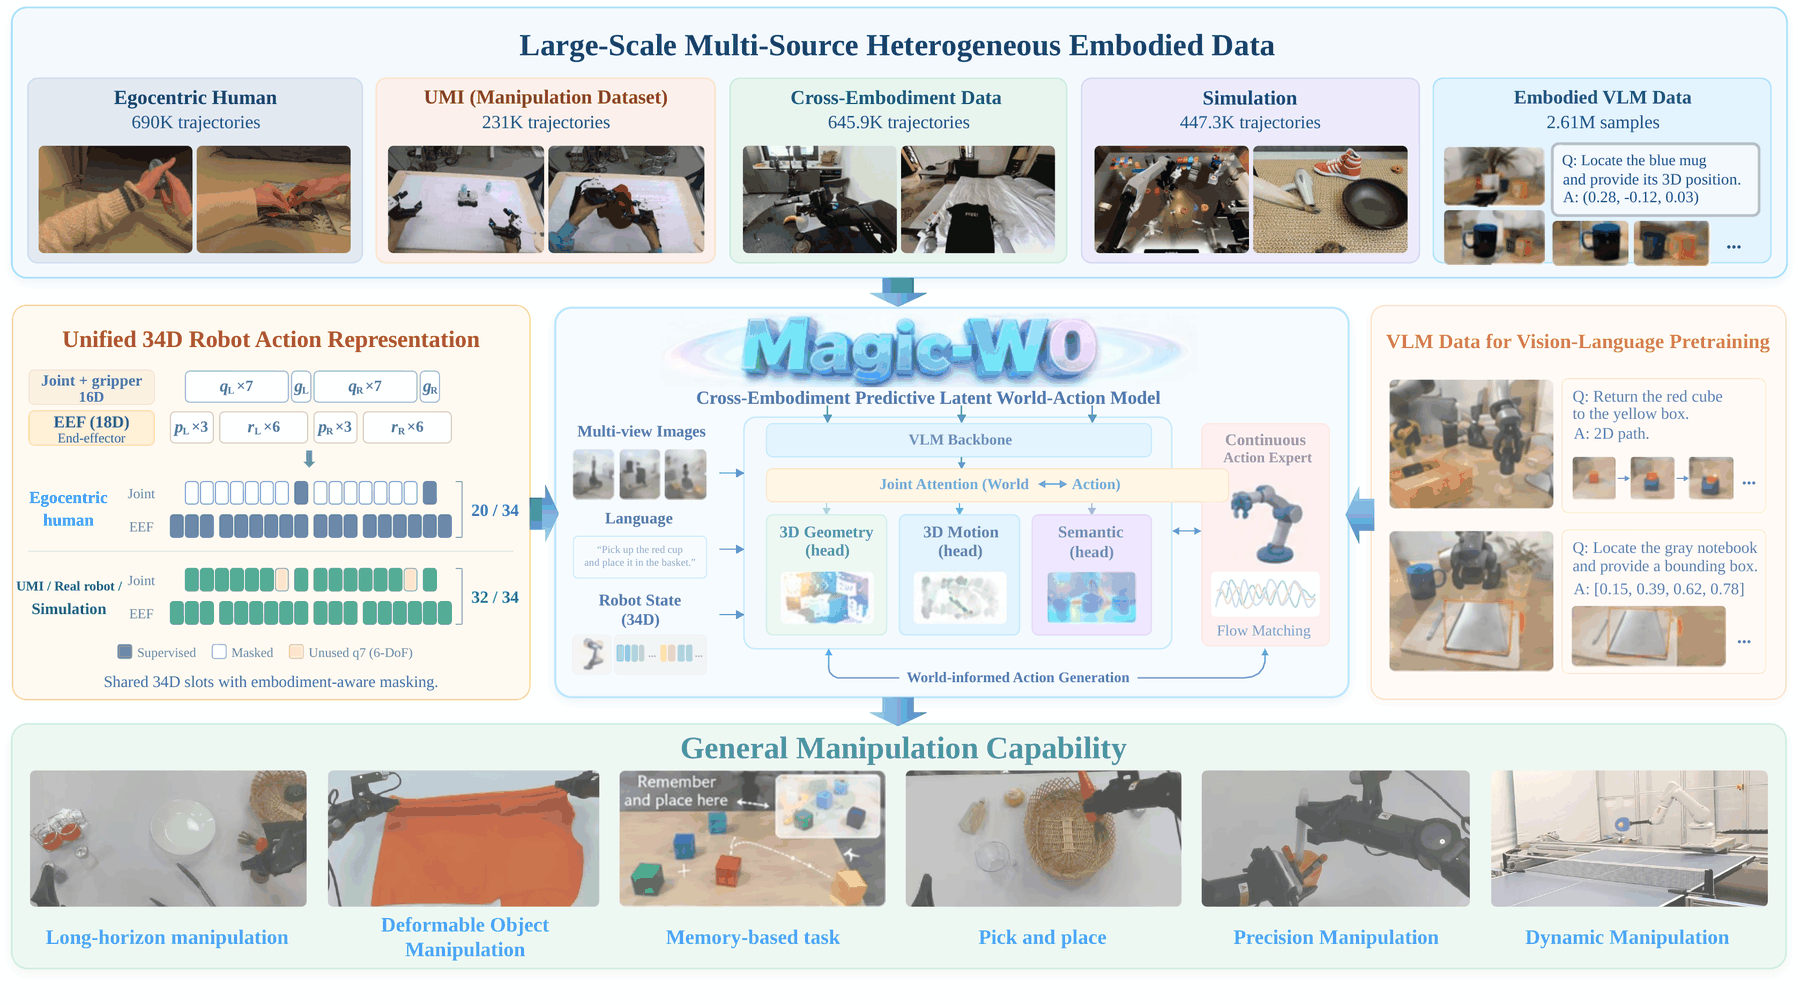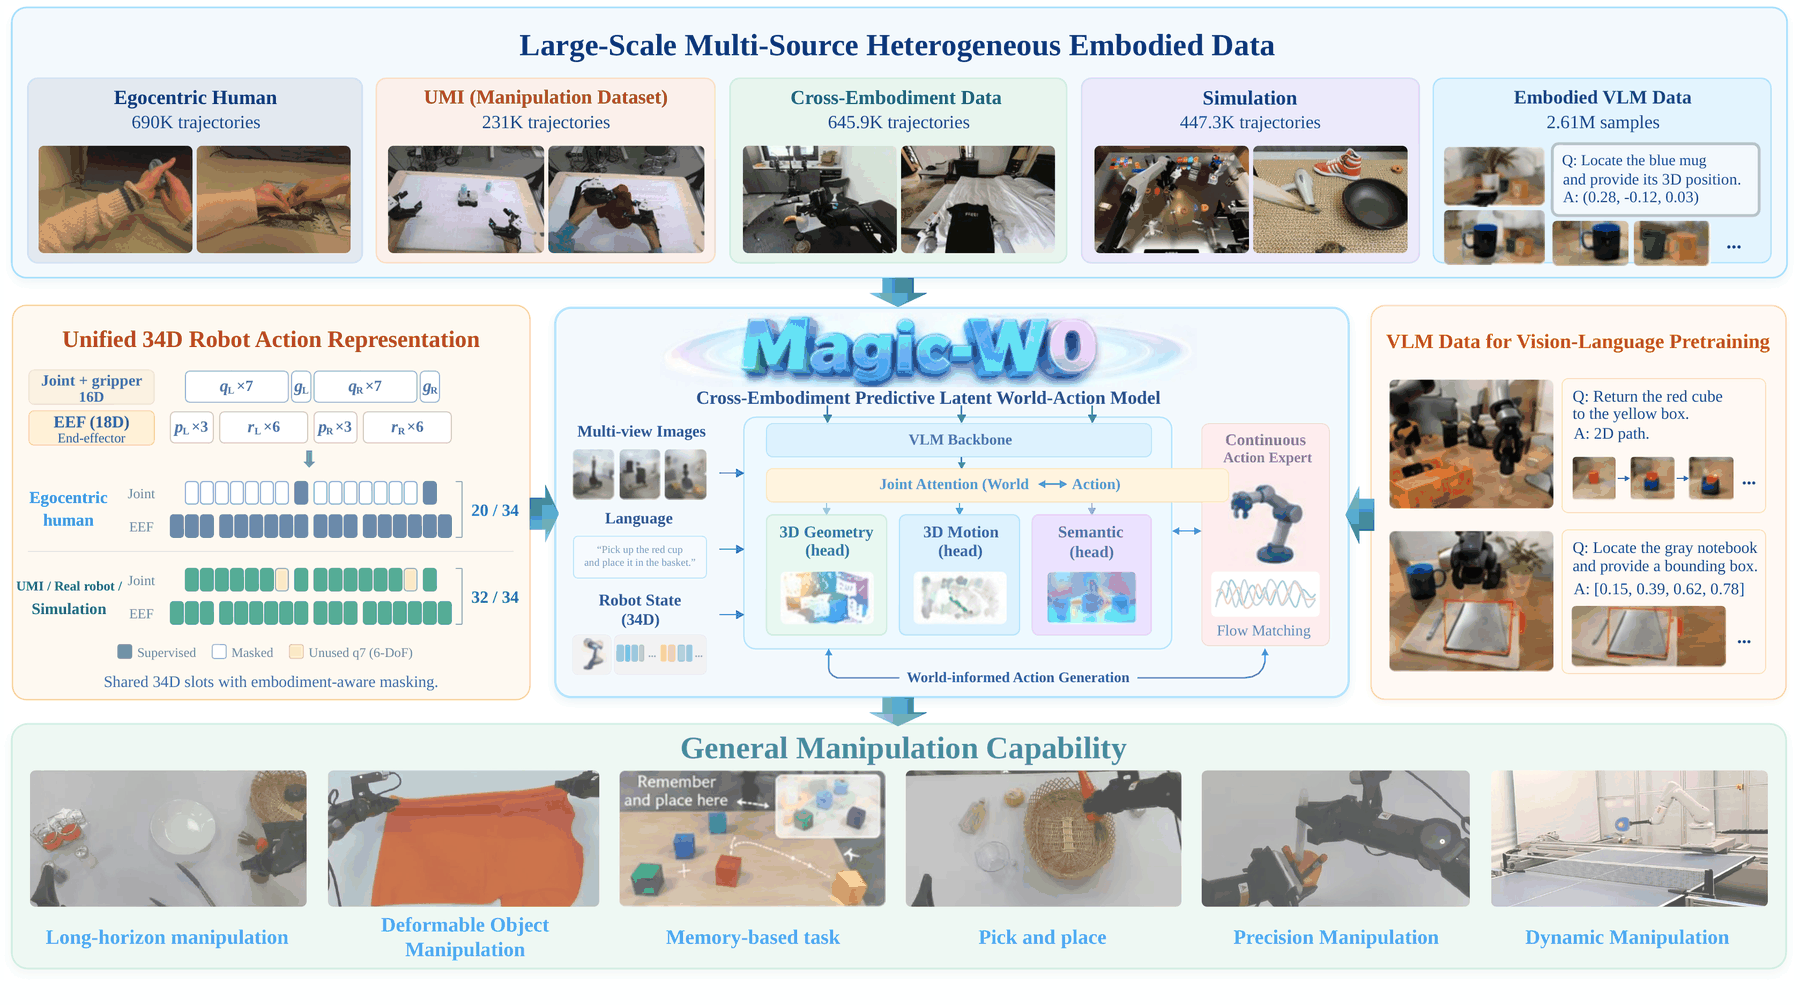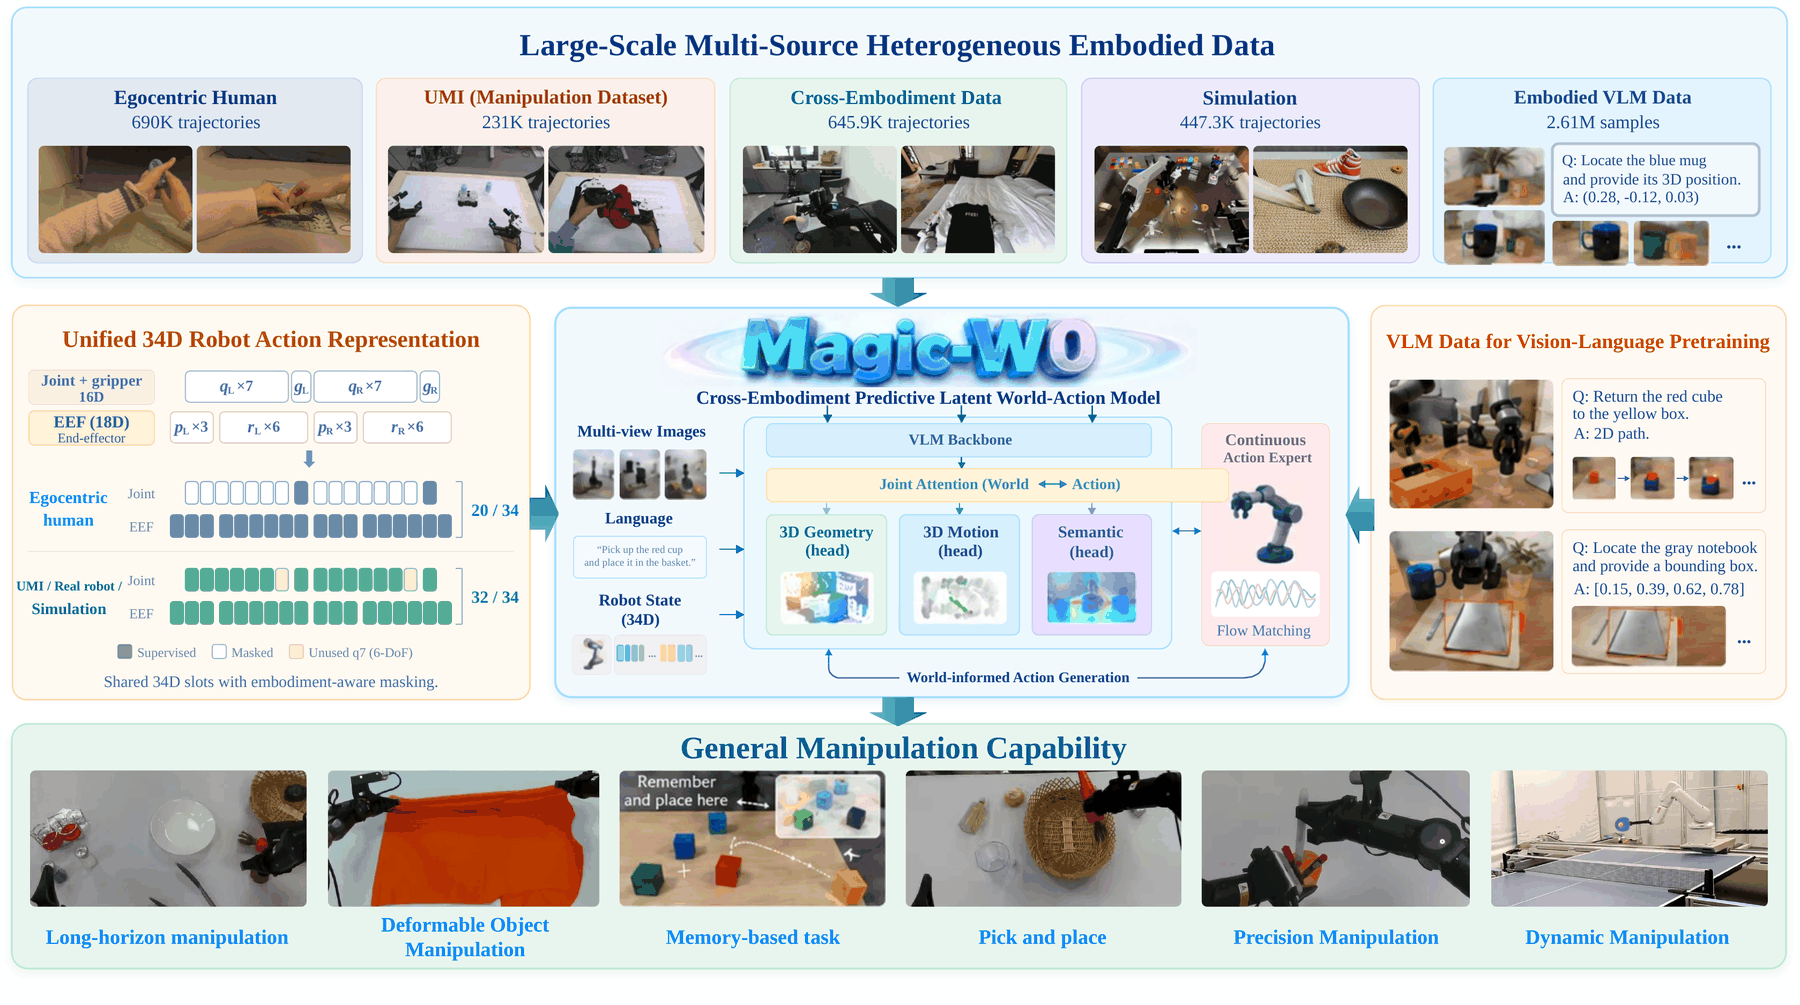
Magic-W0 jointly learns structured world transitions and continuous robot actions from diverse embodied experience. By coupling geometry, motion, and future semantics with action generation, it connects physical world modeling with robotic manipulation.
Key Features
- World–action modeling: jointly learn geometry, motion, future semantics, and continuous actions.
- Cross-embodiment learning: combine human, UMI, real-robot, and simulation experience.
- Teacher-free inference: use world-model supervision during training without running teachers at deployment.
Model Weights
Coming soon. Model weights are not yet available.