
WorldRoPE: Probabilistic World-Centric Rotary Embedding for Multi-View Attention
Paper • 2610.16337 • Published • 1
Probabilistic World-Centric Rotary Embedding for Multi-View Attention
Mijeong Kim · Kyujin Lim · Bohyung Han
Seoul National University
arXiv · Paper · Project Page · Code
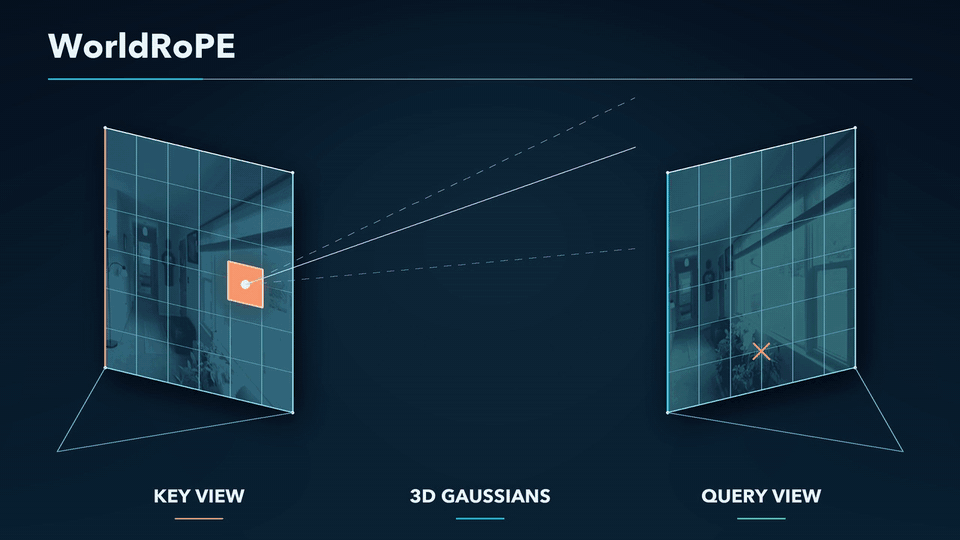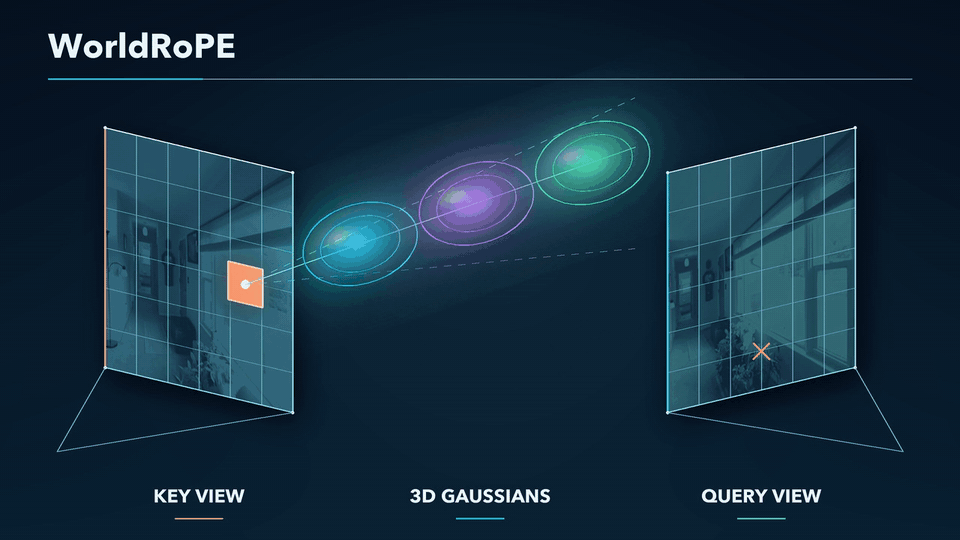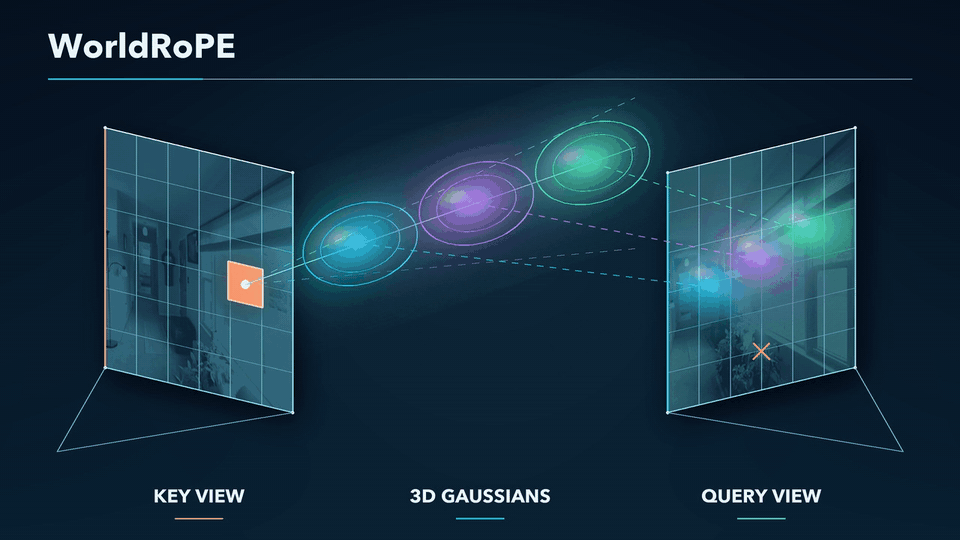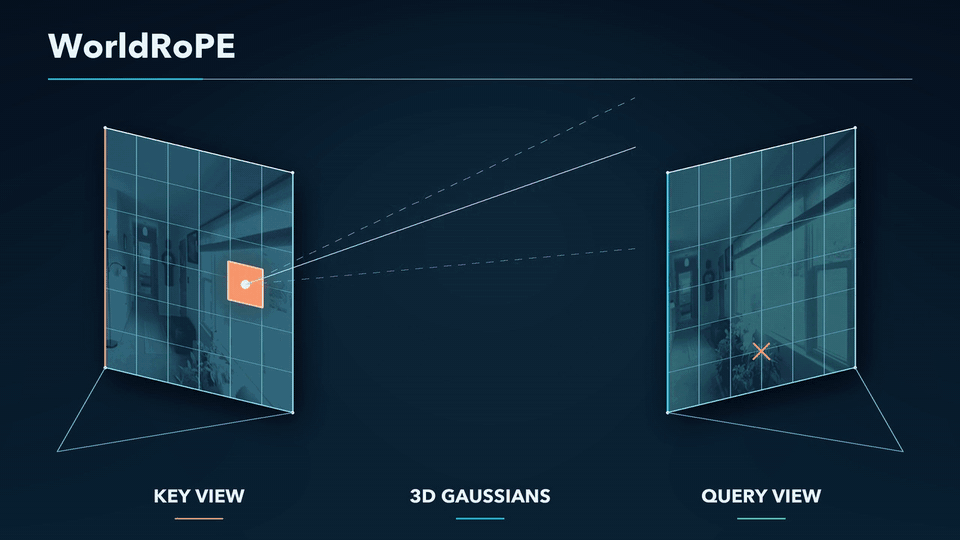
WorldRoPE represents image tokens as probabilistic 3D Gaussian supports and integrates rotary embeddings over their projection into a query view. This repository provides LVSM novel view synthesis checkpoints for WorldRoPE, along with the RayRoPE and URoPE baselines.
| Method | Dataset | Weights | Configuration |
|---|---|---|---|
| RayRoPE (ECCV 2026, spotlight) | RE10K | Download | config.yaml |
| URoPE (ECCV 2026, spotlight) | RE10K | Download | config.yaml |
| WorldRoPE | RE10K | Download | config.yaml |
| WorldRoPE | Objaverse | Download | config.yaml |
hf download mijeongkim/WorldRoPE --local-dir checkpoints
Each checkpoint includes the model tensors and training step, paired with its matching configuration. All four checkpoints are from step 80,000. WorldRoPE and URoPE use 24.5M parameters; RayRoPE uses the official 47.4M small pretrained model from RayRoPE.
Install the code release and prepare the dataset as described in its README. Then verify and evaluate:
python scripts/check_checkpoint.py \
  --checkpoint checkpoints/worldrope_lvsm/re10k/model.pt \
  --config checkpoints/worldrope_lvsm/re10k/config.yaml

bash scripts/nvs.sh --dataset re10k --method worldrope --gpus 0 --test \
  --model-config checkpoints/worldrope_lvsm/re10k/config.yaml \
  --data-root /path/to/re10k \
  --checkpoint checkpoints/worldrope_lvsm/re10k/model.pt \
  --output-dir /path/to/new-evaluation-output
For RayRoPE or URoPE, select --method rayrope or --method urope and use the
corresponding checkpoint and configuration from the table. For Objaverse, use
--dataset objaverse with its checkpoint/configuration and
--fast-dir /path/to/objaverse-packed instead of --data-root.
Reported WorldRoPE results:
| Dataset | PSNR ↑ | SSIM ↑ | LPIPS ↓ |
|---|---|---|---|
| RE10K | 26.75 | 0.846 | 0.073 |
| Objaverse | 22.52 | 0.896 | 0.113 |
@article{kim2026worldrope,
  title={WorldRoPE: Probabilistic World-Centric Rotary Embedding for Multi-View Attention},
  author={Kim, Mijeong and Lim, Kyujin and Han, Bohyung},
  journal={arXiv preprint arXiv:2610.16337},
  year={2026}
}
The baselines build on RayRoPE and URoPE. See LICENSE and upstream notices; RayRoPE retains its MIT license notice.