
Datasets:

image imagewidth (px) 1.92k 1.92k | label class label 3
classes |
|---|---|
0scene1 | |
0scene1 | |
0scene1 | |
0scene1 | |
0scene1 | |
0scene1 | |
1scene2 | |
1scene2 | |
1scene2 | |
1scene2 | |
1scene2 | |
2scene3 | |
2scene3 | |
2scene3 | |
2scene3 | |
2scene3 |

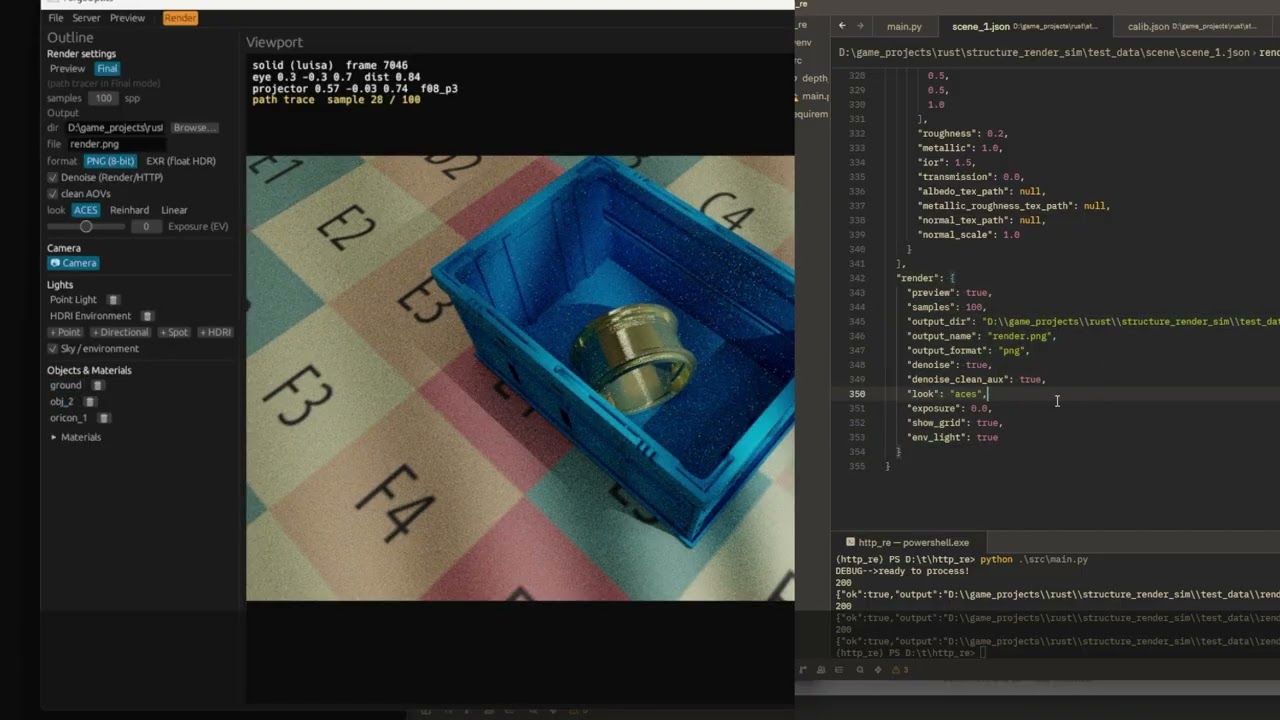
What's Included
Free sample synthetic depth datasets generated deterministically using ForgeOptics — Structured Light Depth Simulator. each sample scene folder contains the following files:
depth_z.exr — Raw 32-bit float metric depth map. Using camera intrinsics (calib), you can reconstruct the true 3D point cloud.
render.png — RGB render output.
seg_index.json — Object-ID segmentation mask mapping and class index metadata.
pointcloud_scene3.ply — Pre-reconstructed 3D point cloud (provided for Scene 3 as an example reference; other raw point clouds are excluded to keep file sizes manageable).
Generated by ForgeOptics
These datasets are produced by ForgeOptics, a high-performance optical simulation engine designed for synthetic data generation. Key Software Features
- Physically Accurate Structured Light Simulation: Simulates multi-frequency phase-shift fringe pattern projection for depth acquisition.
- Complex Optics Path Tracing: Accurately models optical refractions, surface caustics, metallic reflections, and PBR materials.
- AOV Extraction + OIDN Denoising: Extracts clean first-hit G-buffers (Albedo, Normals, Metric Depth) with Open Image Denoise.
- Automated Headless Integration: Runs as an HTTP microservice (--headless) for Python-driven batch generation pipelines.
- Multi-Format Ingestion: Direct CAD model loading (.obj, .glb, .stl).
What Problems Does It Solve?
In computer vision and industrial robotics, acquiring ground-truth depth data for physical sensors is difficult, expensive, and error-prone. ForgeOptics addresses key challenges:
No Sensor Noise / Calibration Overhead: Eliminates the manual labor of capturing and labeling real-world 3D scanner data.
Challenging Optical Surfaces: Solves ground-truth depth generation for hard-to-scan materials like PBR glass, reflective metal, and dark absorbing plastics. Easily swap materials on the same geometry to generate perfect side-by-side ground-truth comparison datasets.
Edge Case Dataset Expansion: Allows rapid generation of thousands of corner-case scenes under varying light conditions and camera poses before real hardware deployment.
Ideal for Vision-Language & Physical AI: Provides perfect, pixel-aligned depth and segmentation ground truth for fine-tuning object detection, instance segmentation, and 3D pose estimation models.
Get the App
To render custom depth datasets with your own CAD models on your local GPU: 👉 Buy ForgeOptics on Gumroad ($199 Perpetual License)
- Native Windows (CUDA / DX12) and Linux (CUDA 12 / OptiX) binaries
- Includes interactive GUI mode and Headless HTTP server mode (
--headless)
How to use:
uv venv --python 3.11
uv pip install -r requirements.txt
⚡ Quick Start & Visualization
python ./src/main.py -> batch process with your scene setting
python ./src.depth_visualizer.py -> for checkign the depth results
Acknowledgments
This project builds upon LuisaRender, used under the BSD 3-Clause License. Copyright (c) LuisaGroup.
- Downloads last month
- 74