

CaiYuanhao/SAX-NeRF
Updated • 1
The dataset viewer is not available because its heuristics could not detect any supported data files. You can try uploading some data files, or configuring the data files location manually.

15 scenes · 4 application domains · Sparse-view CT reconstruction · X-ray novel view synthesis
 |
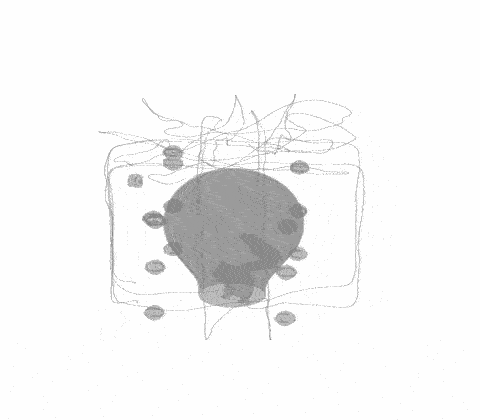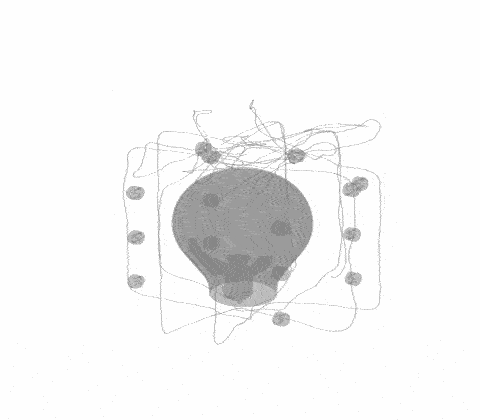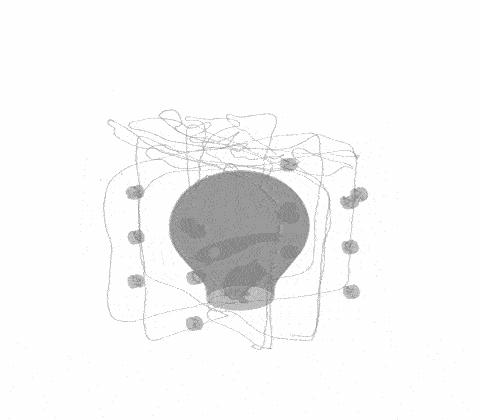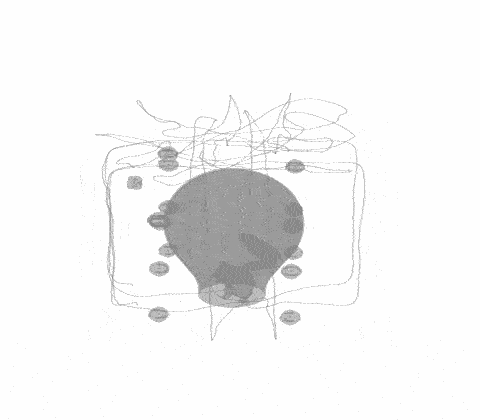 |
 |
Backpack |
Box |
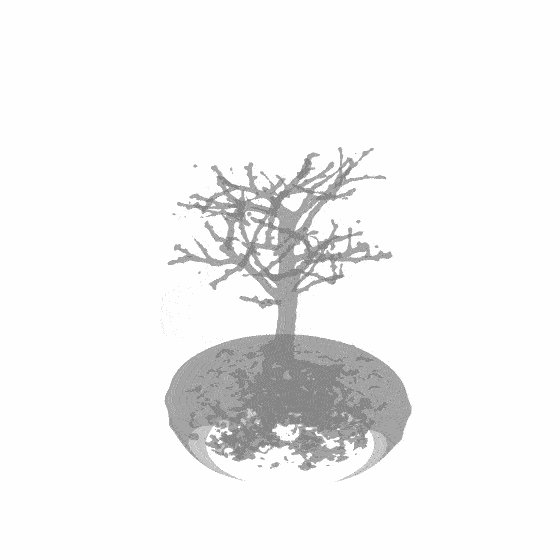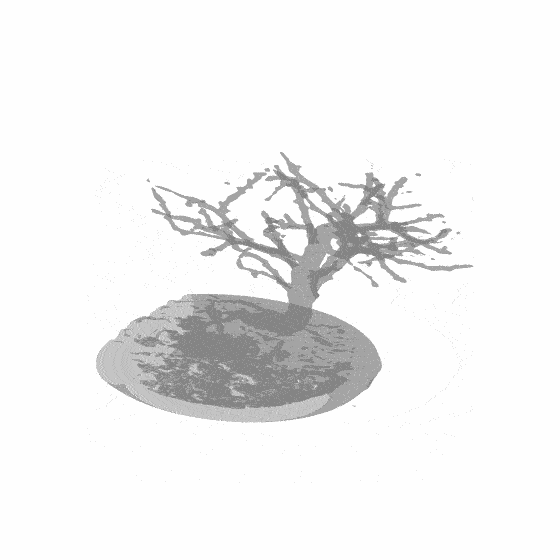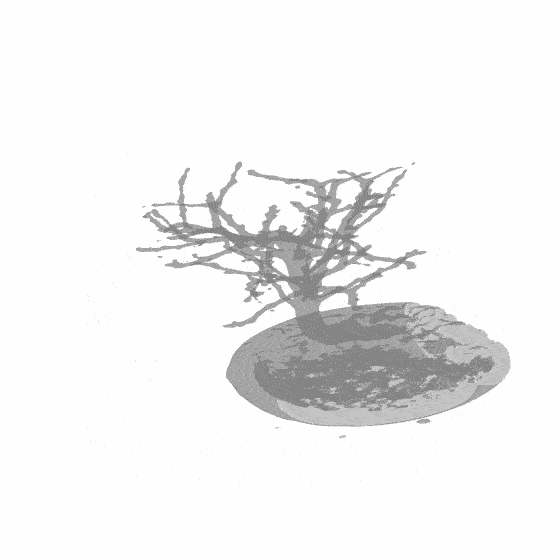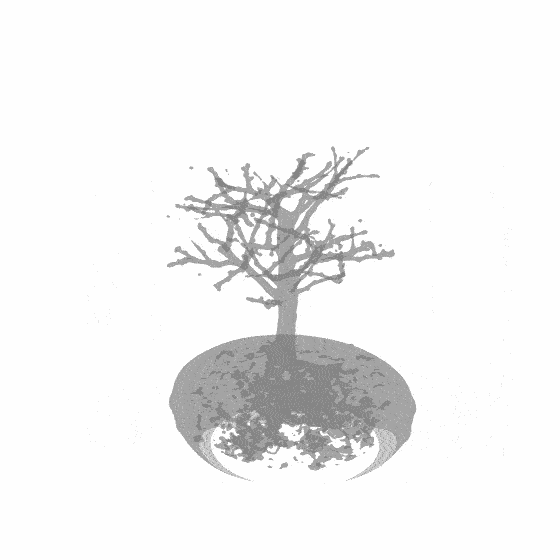
Bonsai |
 |
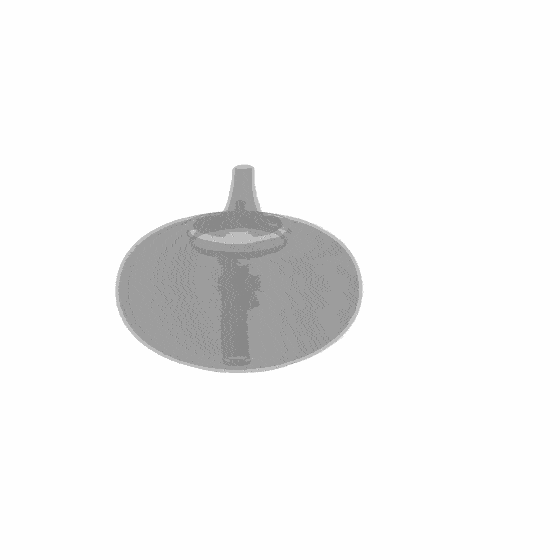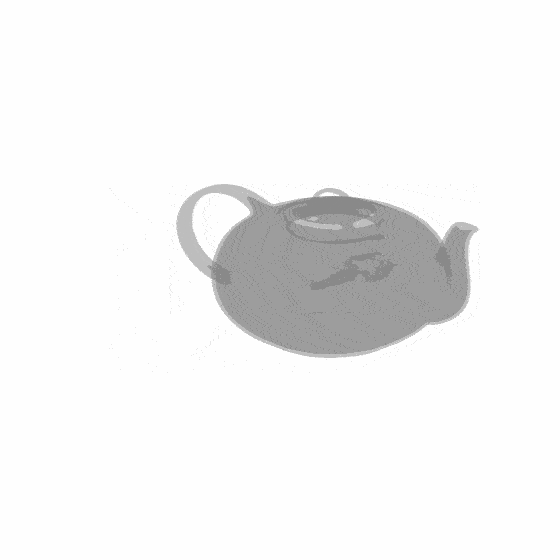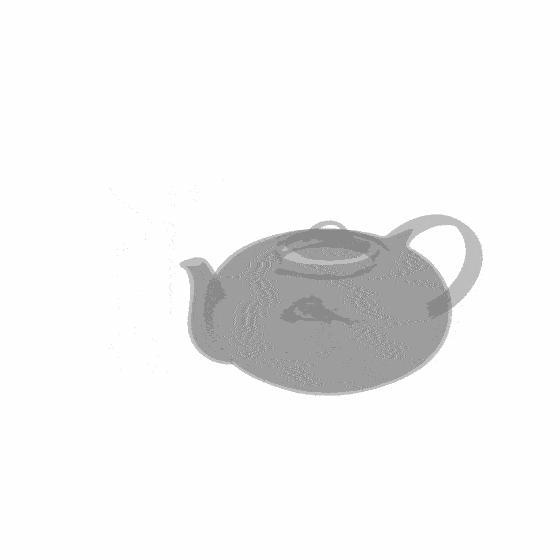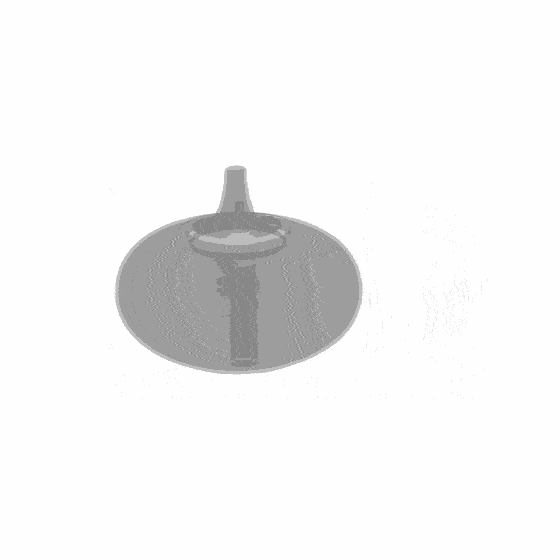 |
 |
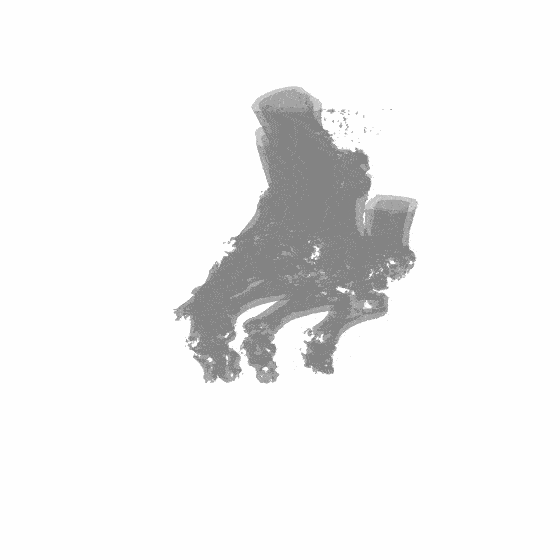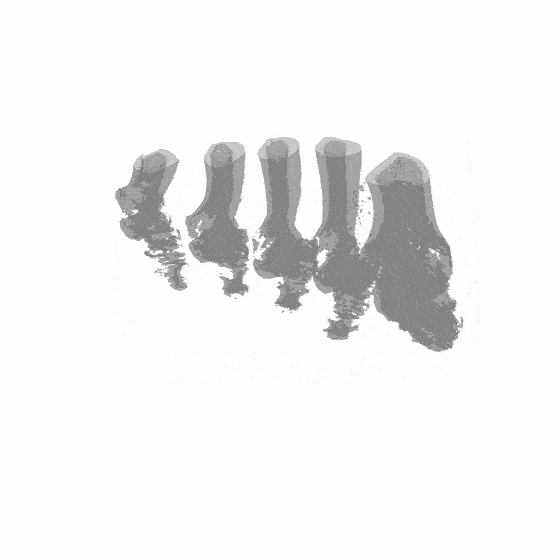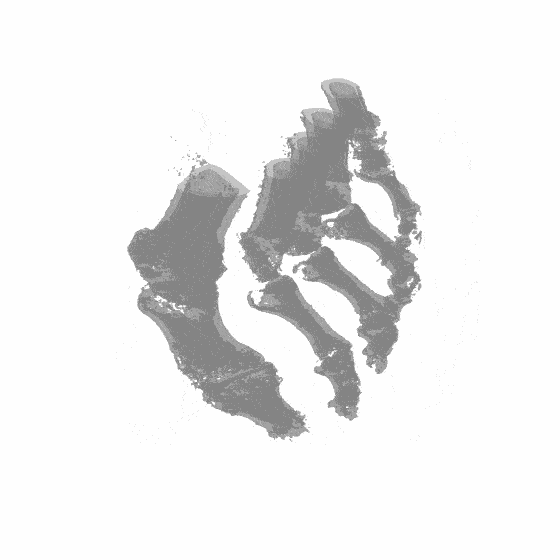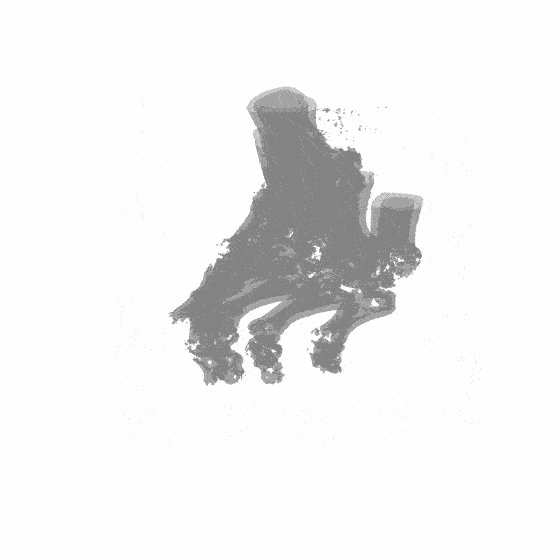
Foot |
Teapot |
Engine |
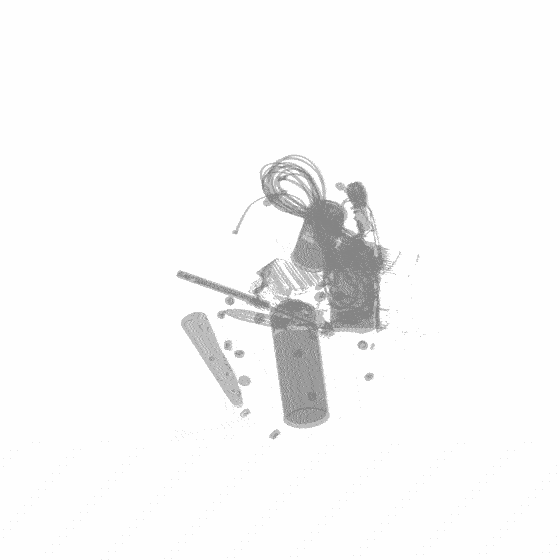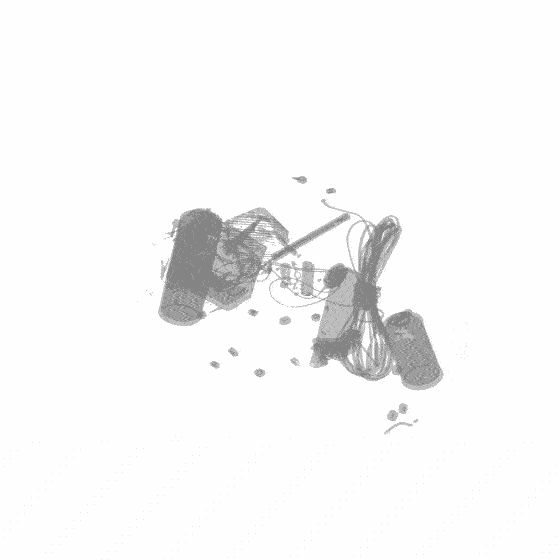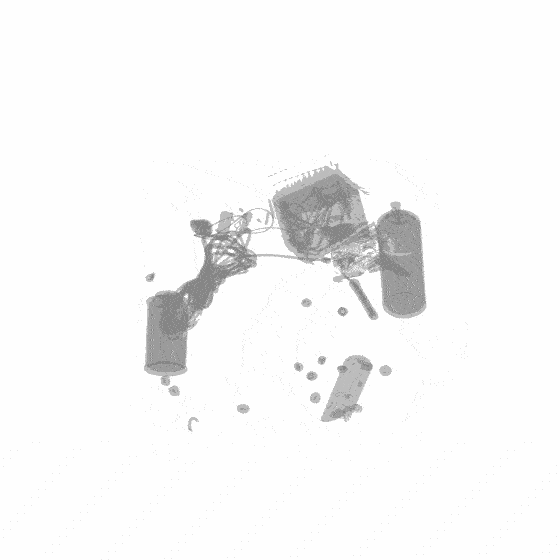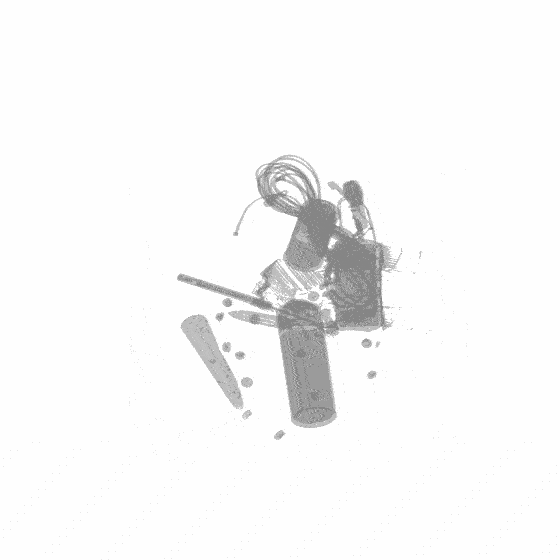
Reconstruction visualizations from the official SAX-NeRF repository; the downloadable dataset consists of processed scene arrays.
This repository hosts the processed X3D dataset released with SAX-NeRF, introduced in Structure-Aware Sparse-View X-ray 3D Reconstruction (CVPR 2024). It supports research on sparse-view CT reconstruction and X-ray novel view synthesis.
X3D contains 15 scenes spanning medicine, biology, security, and industry. Projections are synthesized from publicly available CT volumes using TIGRE. The paper describes scanning over 0°–180° with 3% noise, using 50 training projections and 50 evaluation projections per scene. The reference CT volume is used to evaluate reconstruction quality. See the paper, Section 4.1.
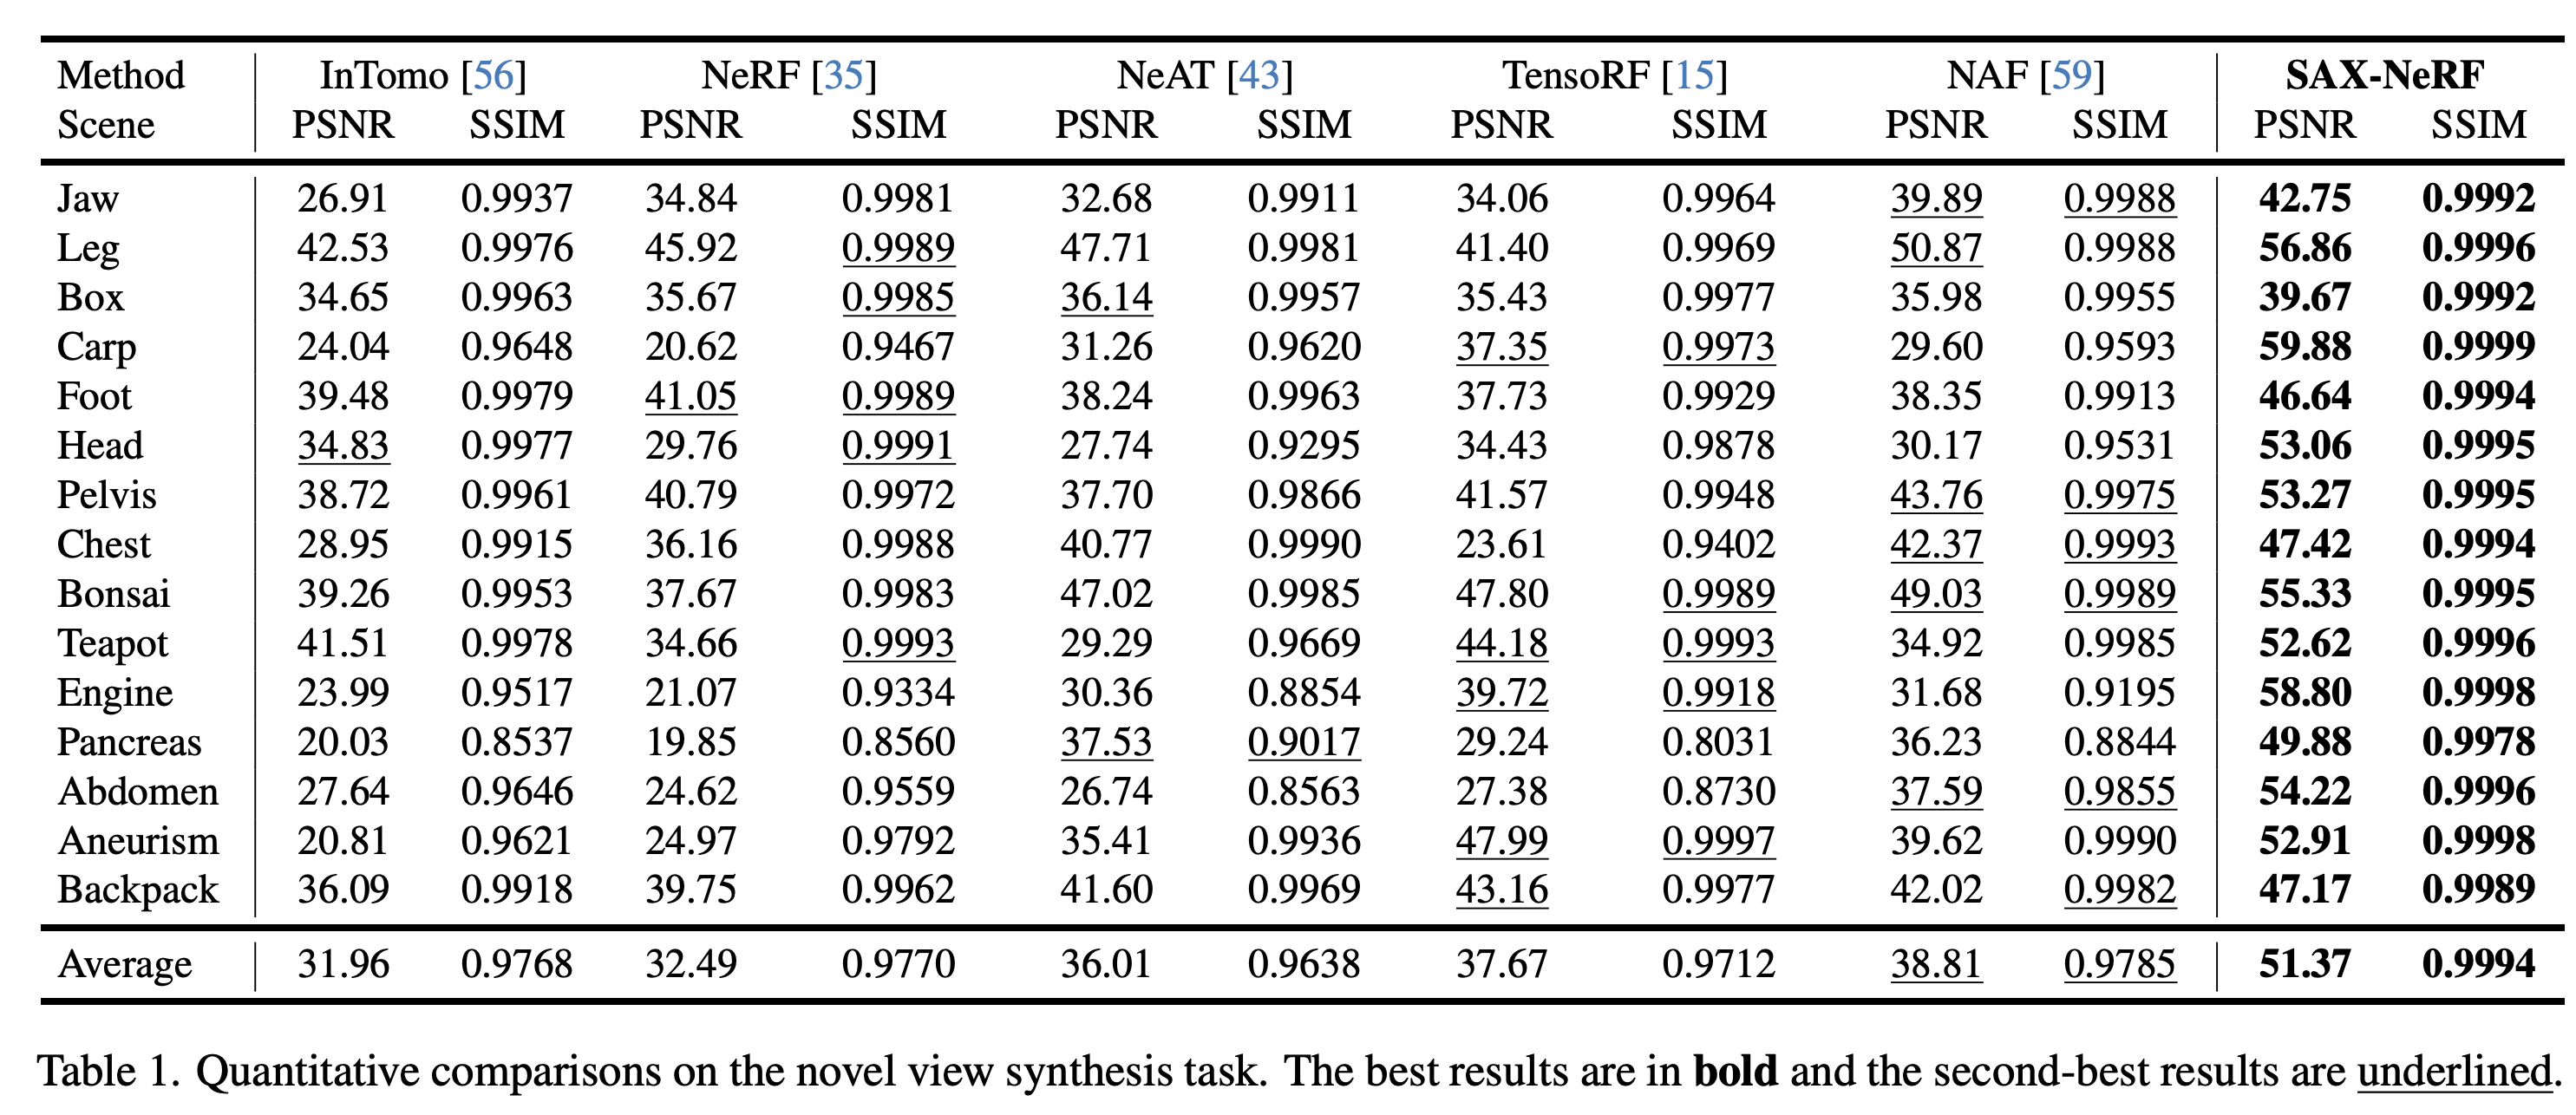
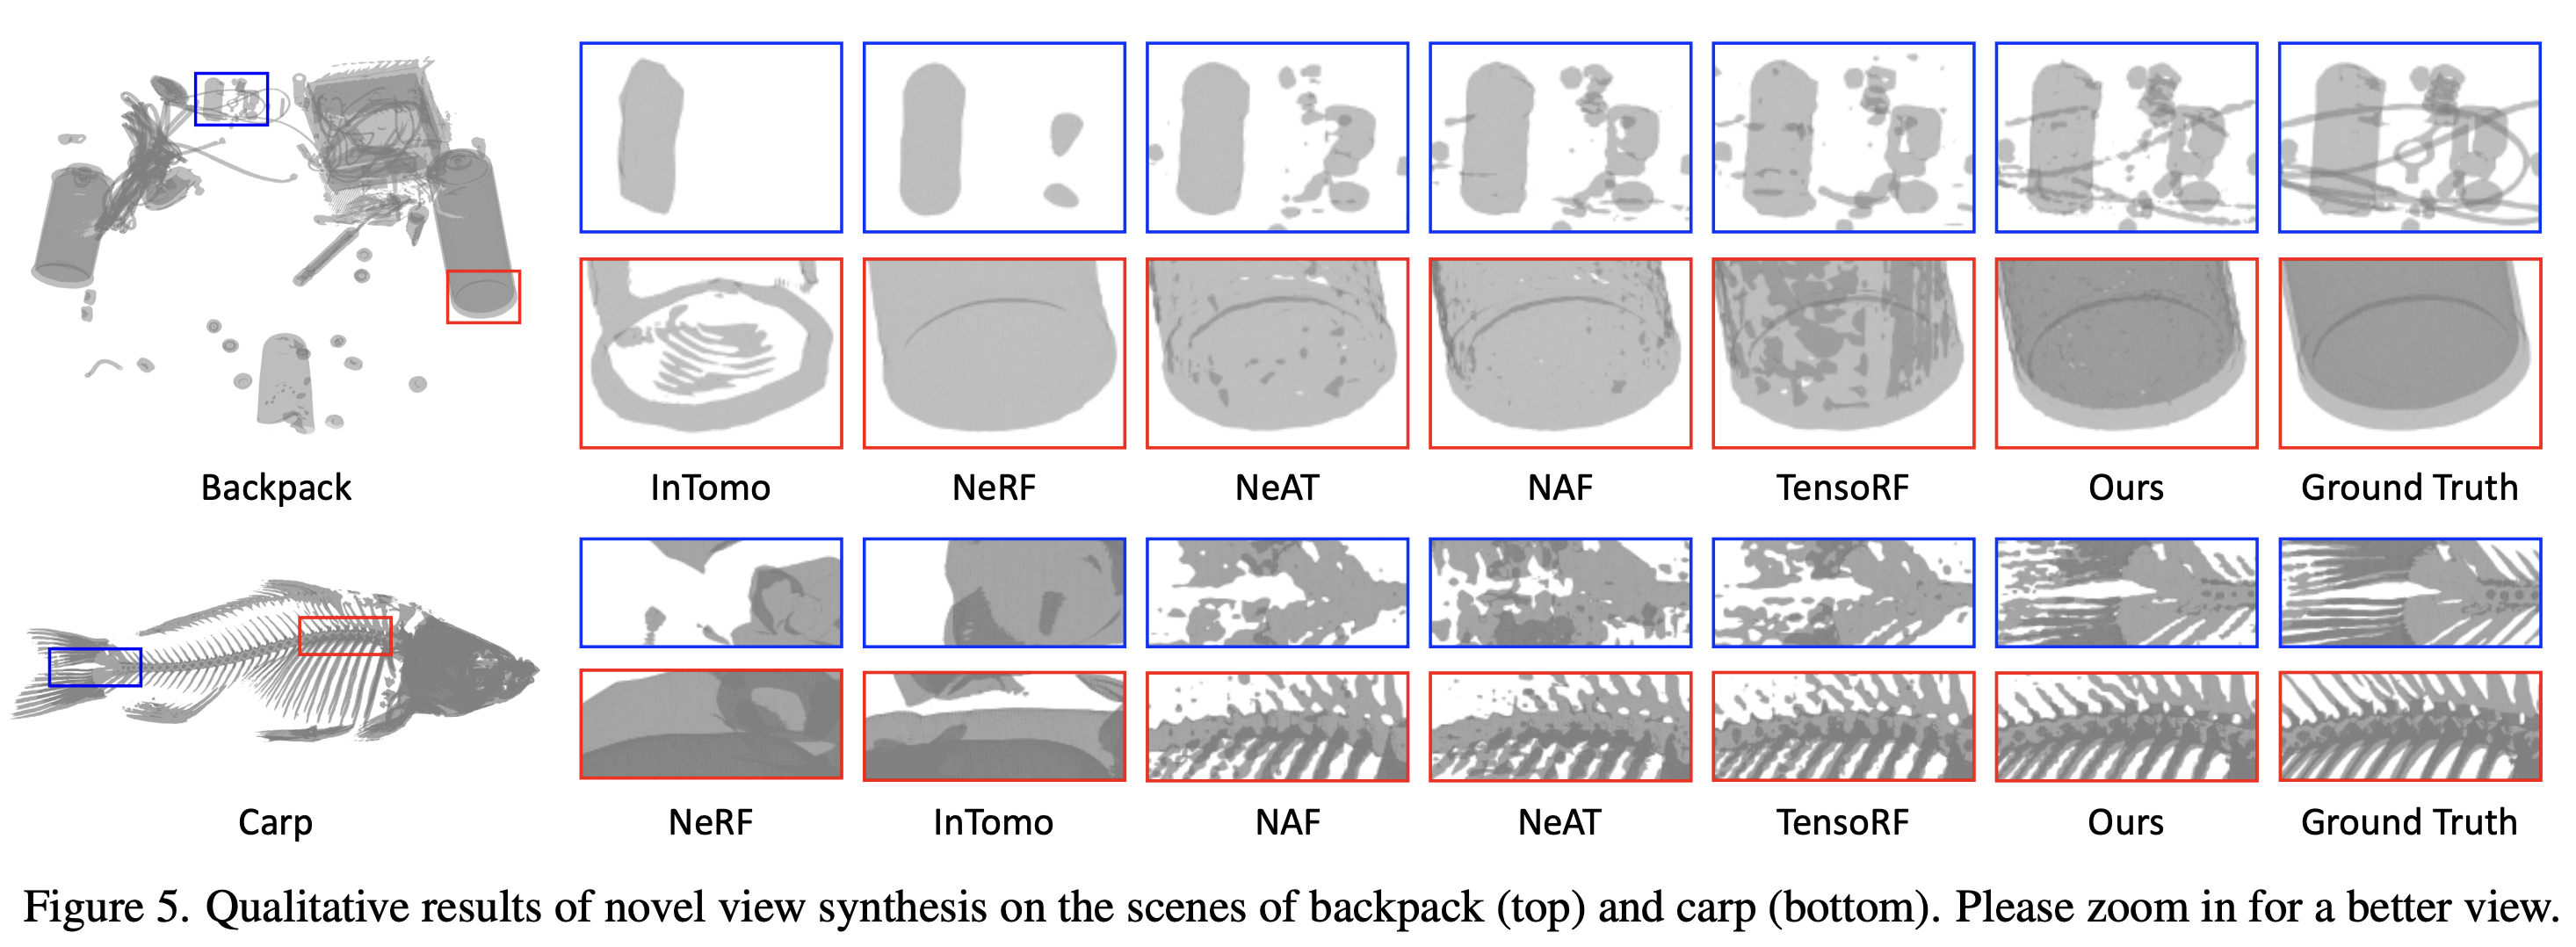
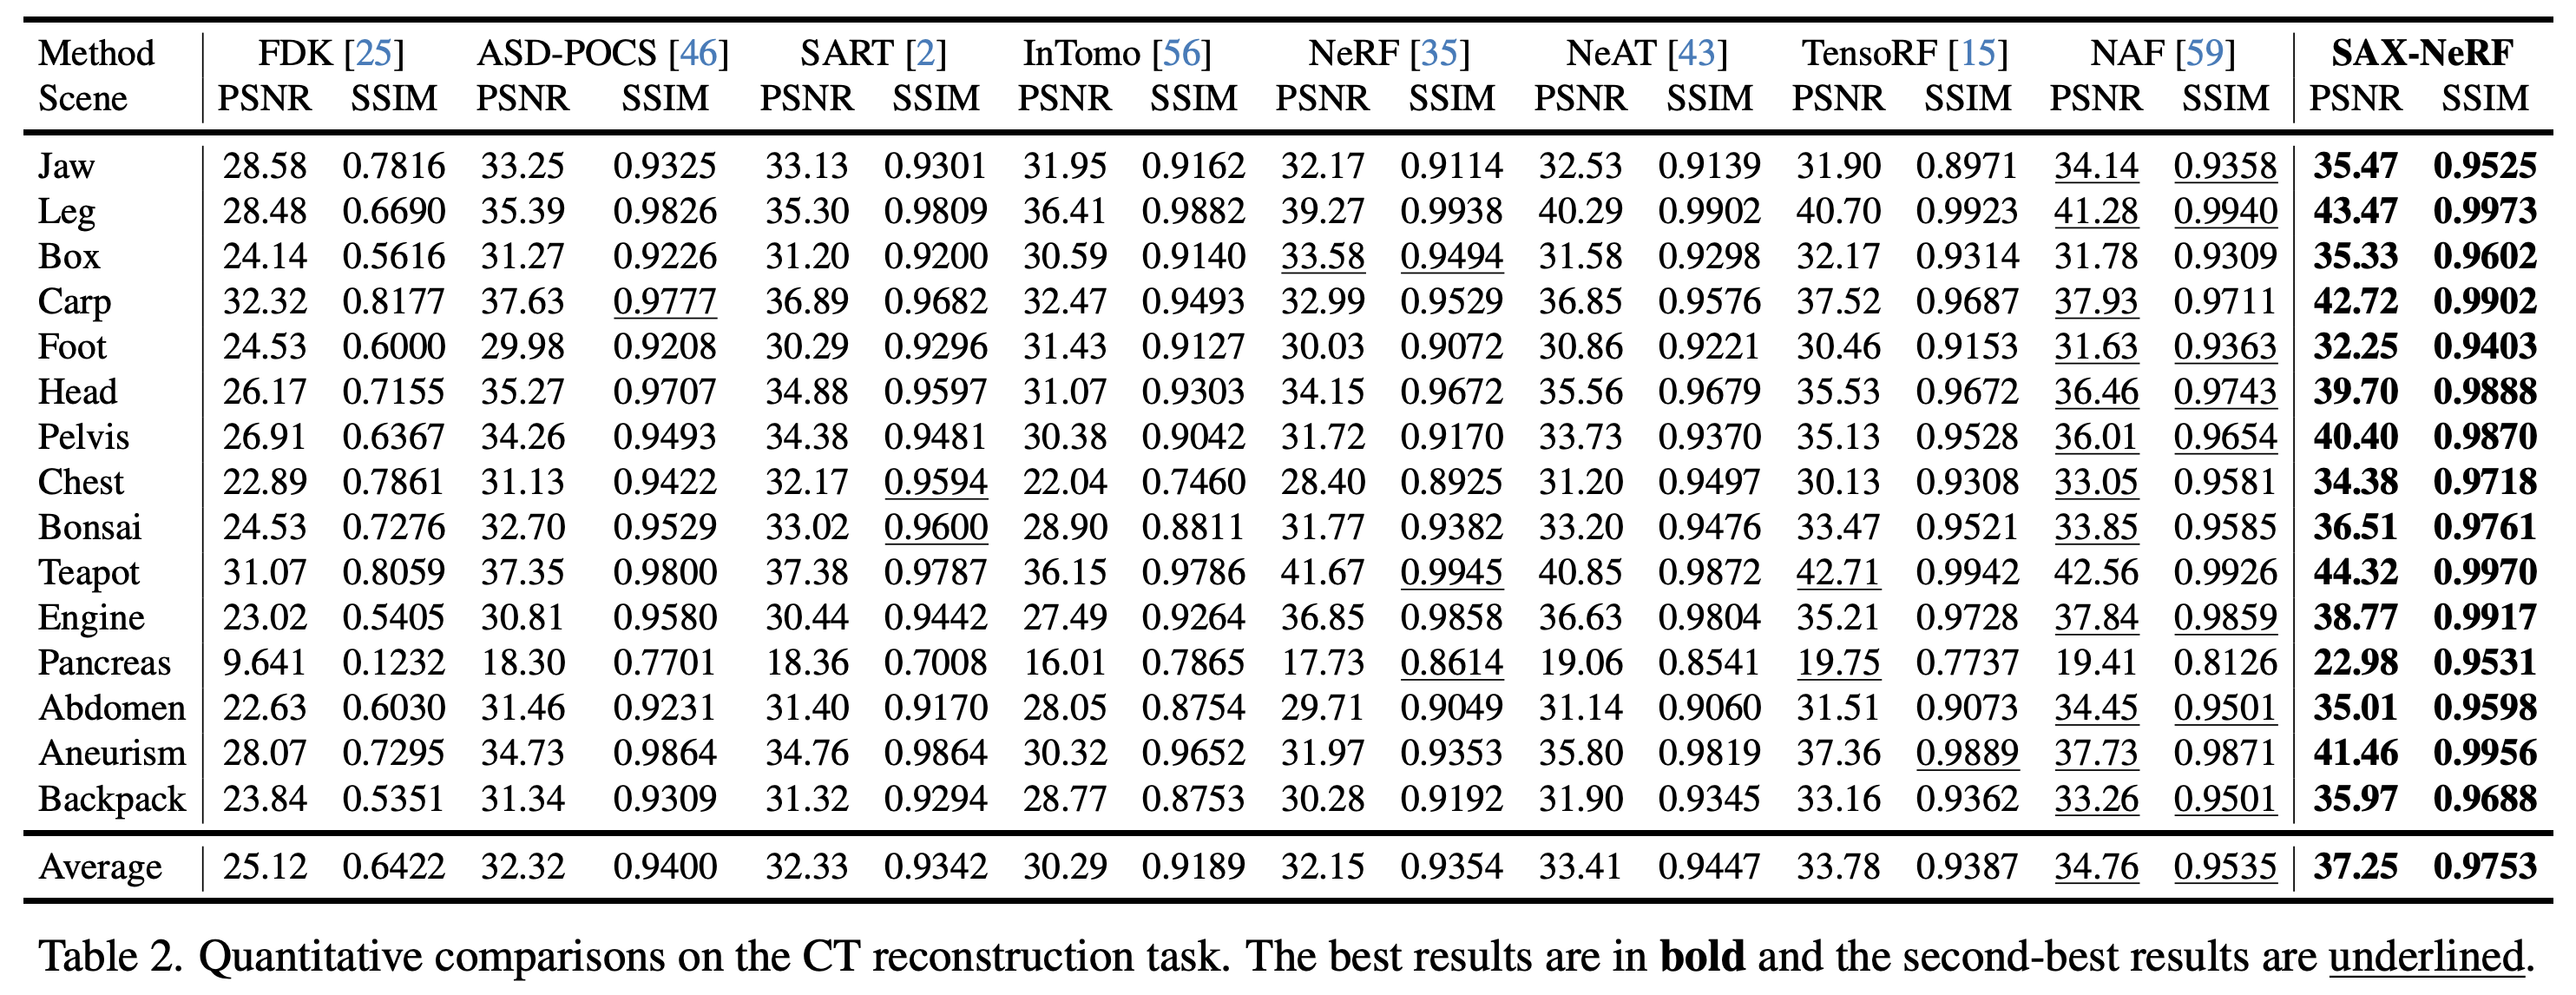
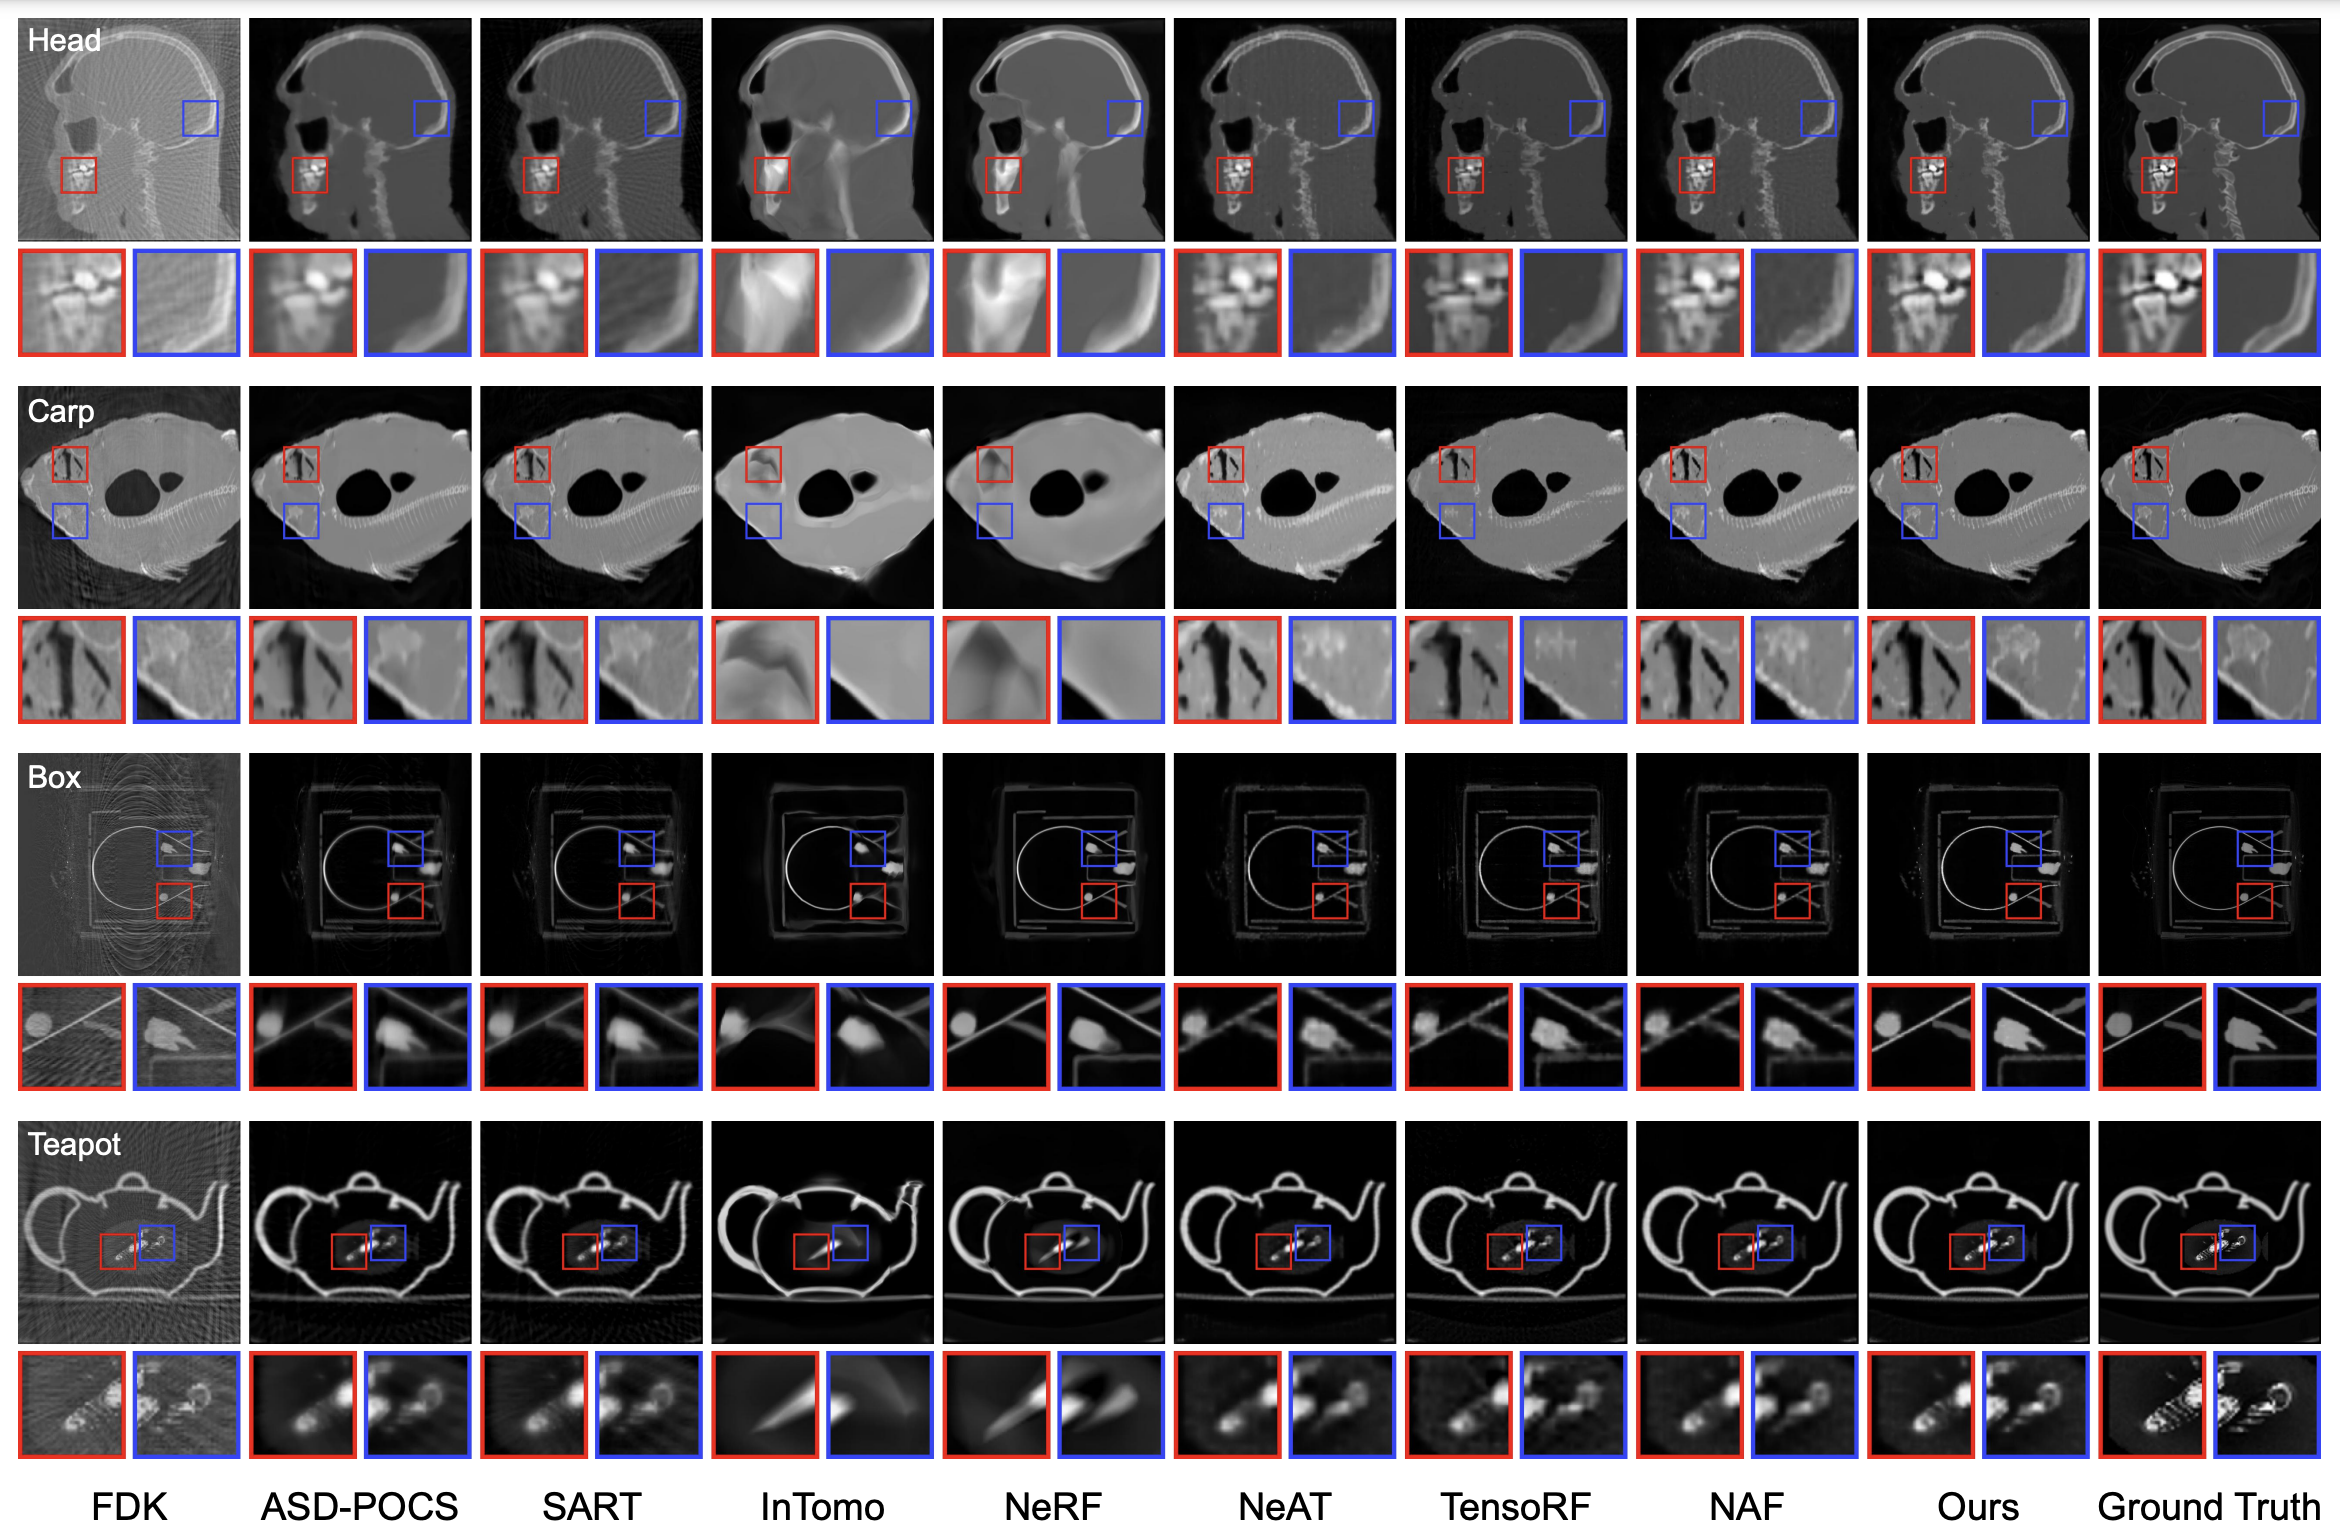
Comparison figures reproduced from the official project repository.
The dataset repository provides one processed Python pickle file per scene:
SAX-NeRF/
├── abdomen_50.pickle
├── aneurism_50.pickle
├── backpack_50.pickle
├── bonsai_50.pickle
├── box_50.pickle
├── carp_50.pickle
├── chest_50.pickle
├── engine_50.pickle
├── foot_50.pickle
├── head_50.pickle
├── jaw_50.pickle
├── leg_50.pickle
├── pancreas_50.pickle
├── pelvis_50.pickle
└── teapot_50.pickle
The following schema follows the project's data generator and dataset loader. Array dimensions and geometry parameters should be read from each scene file.
| Field | Description |
|---|---|
image |
Reference 3D CT volume. |
train.projections |
Training projections, indexed by view, with shape (N_train, H, W). |
train.angles |
Training view angles in radians. |
val.projections |
Held-out projections, with shape (N_val, H, W). |
val.angles |
Held-out view angles in radians. |
numTrain, numVal |
Numbers of training and held-out views. |
DSD, DSO |
Source-to-detector and source-to-origin distances. |
nDetector, dDetector |
Detector pixel counts and pixel sizes. |
nVoxel, dVoxel |
Volume voxel counts and voxel sizes. |
offOrigin, offDetector |
Volume and detector offsets. |
mode, accuracy, filter |
Geometry and reconstruction settings. |
The loader converts physical distances from millimeters to meters. The held-out projection set is named val in the code and is used for novel view synthesis testing in the paper. These are view splits within a scene, rather than disjoint sets of scenes.
Install the download client and NumPy:
pip install huggingface_hub numpy
Download a single scene and inspect its arrays:
import pickle
from huggingface_hub import hf_hub_download

path = hf_hub_download(
    repo_id="CaiYuanhao/SAX-NeRF",
    repo_type="dataset",
    filename="chest_50.pickle",
)

# Only deserialize pickle files from a trusted source.
with open(path, "rb") as f:
    scene = pickle.load(f)

print("CT volume:", scene["image"].shape)
print("Training projections:", scene["train"]["projections"].shape)
print("Held-out projections:", scene["val"]["projections"].shape)
print("Training angles:", scene["train"]["angles"].shape)
To download all processed scenes:
from huggingface_hub import snapshot_download

snapshot_download(
    repo_id="CaiYuanhao/SAX-NeRF",
    repo_type="dataset",
    allow_patterns=["*.pickle"],
    local_dir="data",
)
Run the command above from the SAX-NeRF project root to place the files in its expected data/ directory. After setting up the environment described in the project README, train on the chest scene with:
python train_mlg.py --config config/Lineformer/chest_50.yaml
The paper attributes chest, backpack, carp, and pancreas to LIDC-IDRI, MIDA, D²VR, and DeepOrgan, respectively; teapot, aneurism, bonsai, and foot to VOLVIS; and the remaining scenes to an open scientific visualization dataset. See Section 4.1 and references therein for the reported provenance.
The released generation code loads CT volumes, applies configured preprocessing, and generates projections and associated scanning geometry. Consult the data generation code when creating additional scenes or changing acquisition settings.
If you use this dataset, please cite the SAX-NeRF paper. The entry below follows the citation supplied by the official code repository:
@inproceedings{sax_nerf,
  title={Structure-Aware Sparse-View X-ray 3D Reconstruction},
  author={Yuanhao Cai and Jiahao Wang and Alan Yuille and Zongwei Zhou and Angtian Wang},
  booktitle={CVPR},
  year={2024}
}