

Reinforcing End-to-End Autonomous Driving Safety via Negative-Aware Planning in a Unified World-Action Model
Paper • 2611.08111 • Published
Reinforcing End-to-End Autonomous Driving Safety via Negative-Aware Planning in a Unified World-Action Model
Paper · Code & Setup · Model Files
NegWAM is a safety post-training framework for unified world-action models in end-to-end autonomous driving. It learns from near-expert failure trajectories: unsafe alternatives that remain geometrically close to expert trajectories. Repulsive anchors steer predictions away from these alternatives, while scene-conditioned rider tokens learn scene–trajectory compatibility. The auxiliary rider branch is used during training and omitted from the inference path.
This repository provides the NegWAM Transformer weights, model configuration, and NAVSIM v2 evaluation results. Use the custom model implementation and evaluation tools in the GitHub repository to run the model.
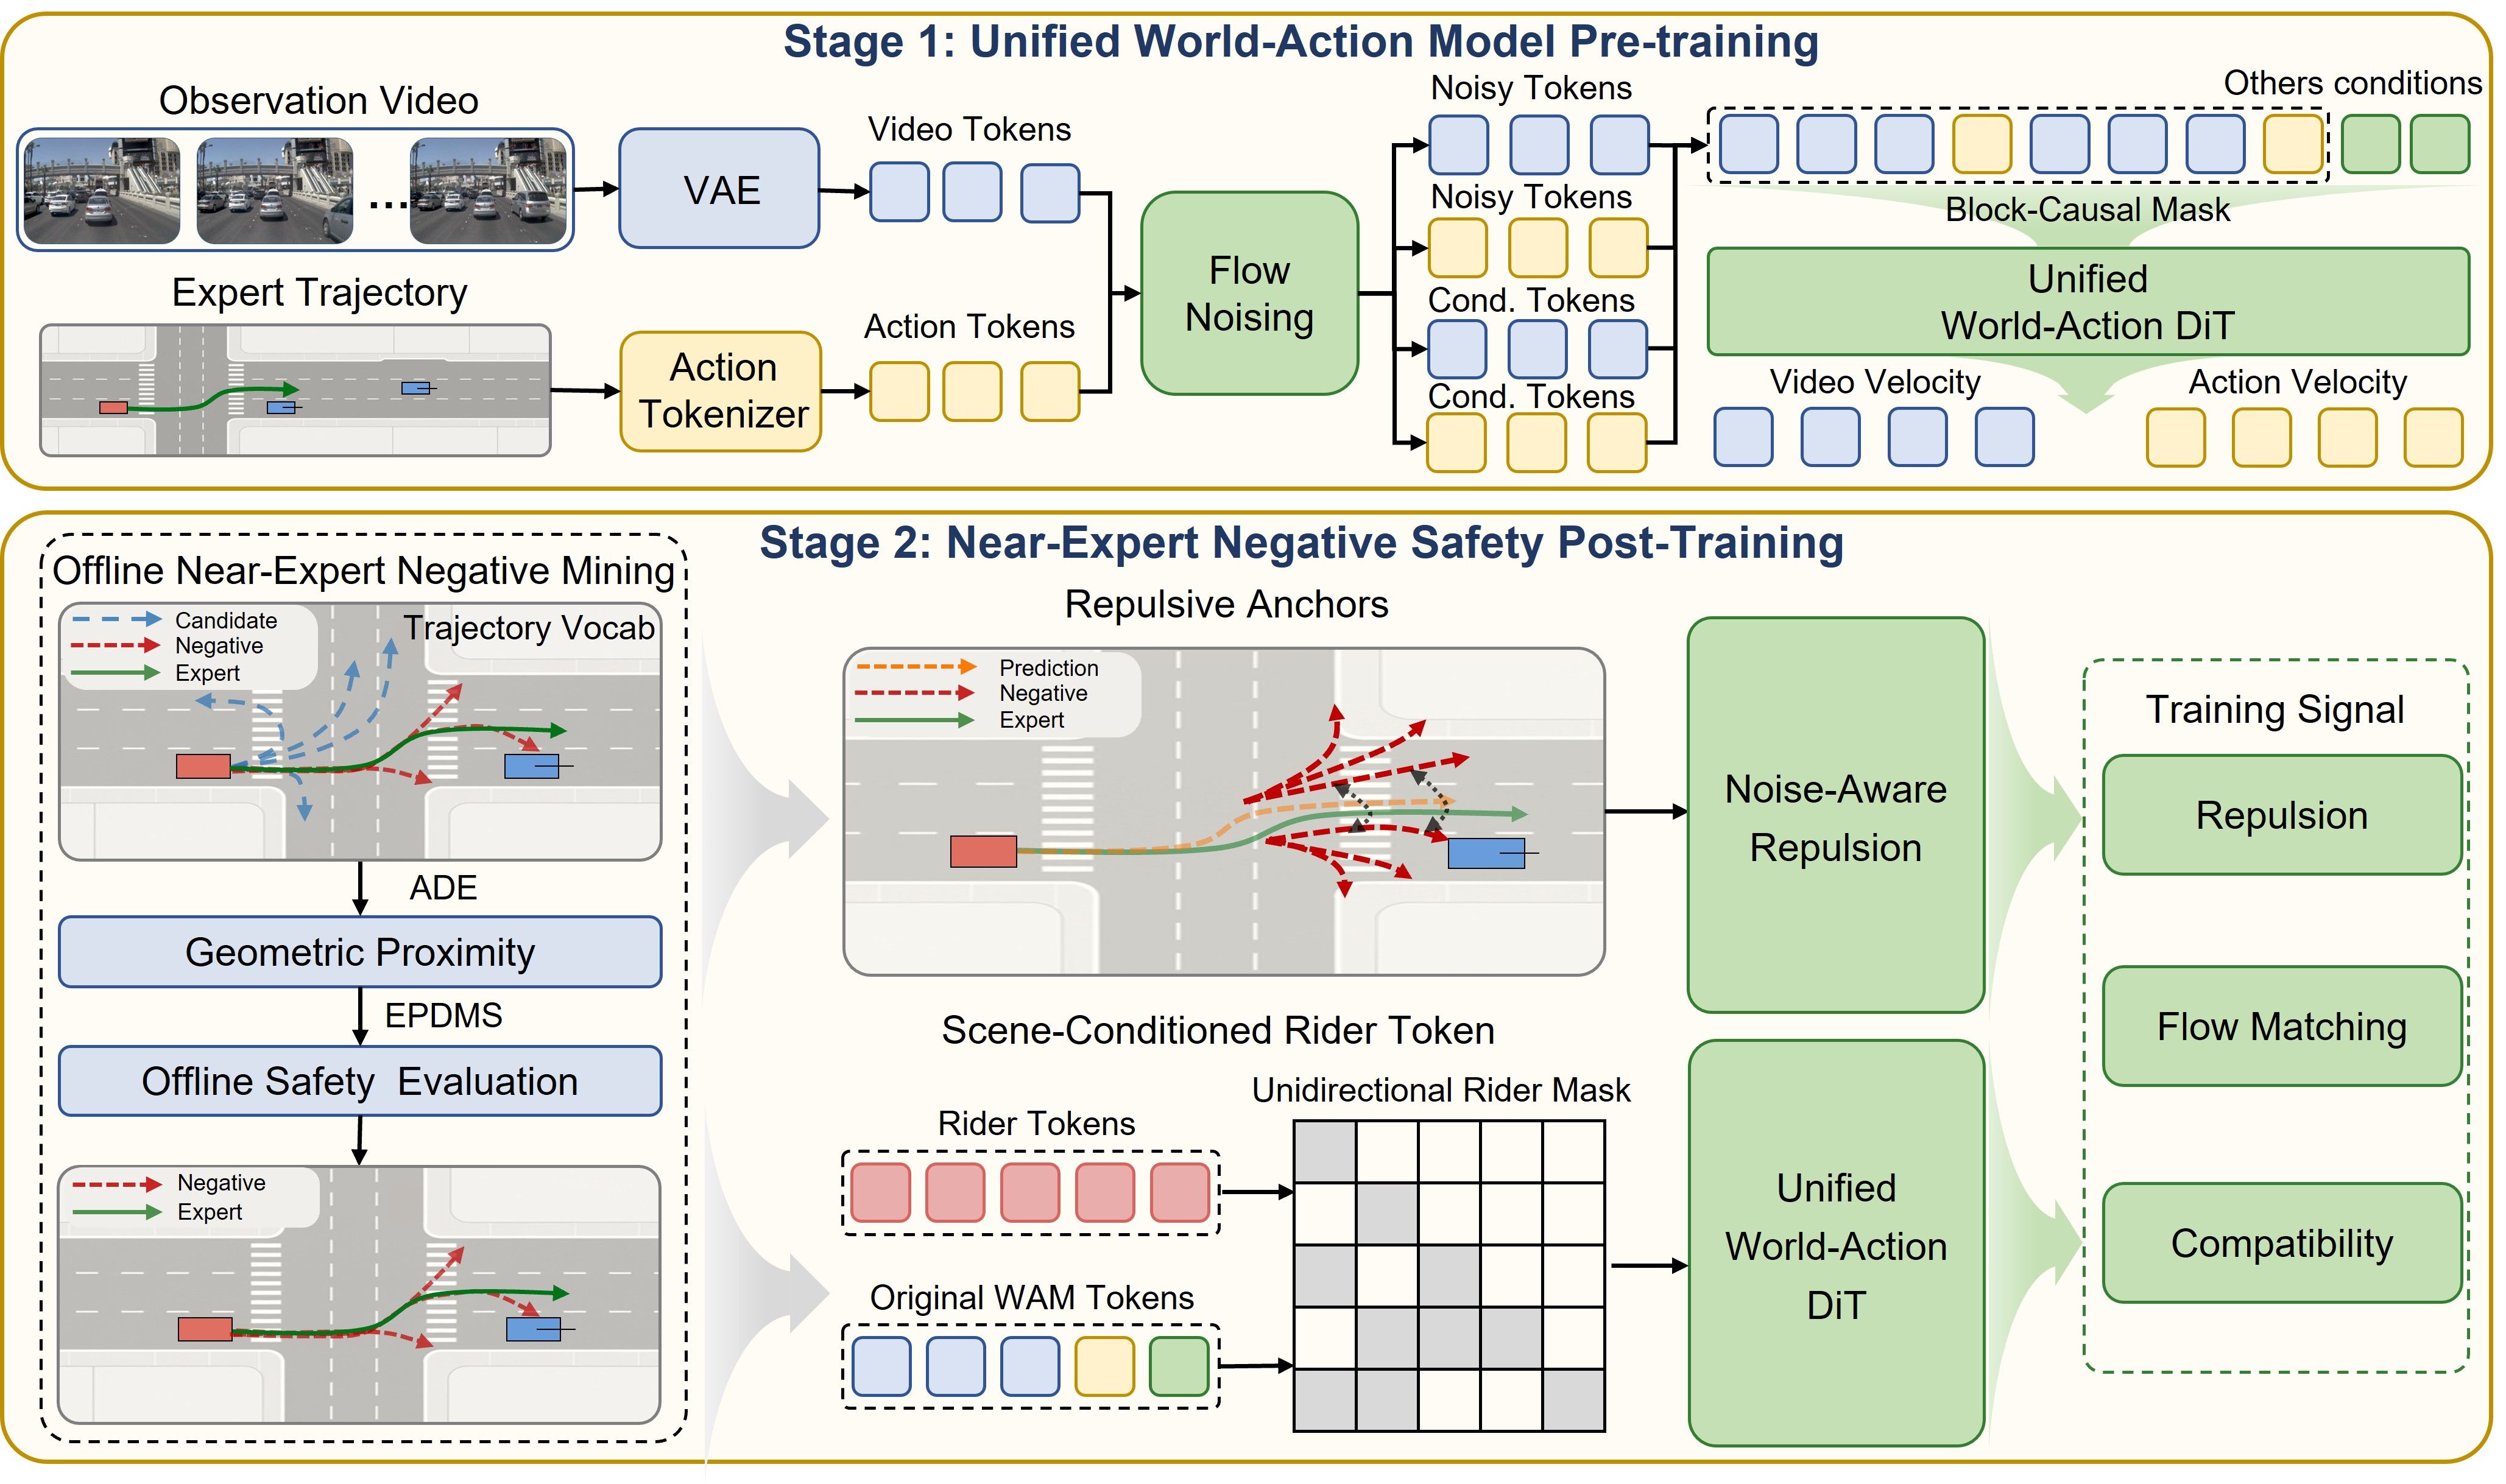
| Property | Value |
|---|---|
| Task | End-to-end autonomous driving / ego-trajectory planning |
| Model class | WanTransformer3DNavSimModel (custom Diffusers-based implementation) |
| Conditioning | Camera observations, ego state/history, and navigation commands |
| Planning output | 8 ego poses (x, y, heading) over 4 seconds at 0.5-second intervals through the NAVSIM agent |
| Weight format | Safetensors, BF16 |
| Weight file size | Approximately 12.49 GB |
| License | Apache 2.0 |
| File | Description |
|---|---|
config.json |
Architecture configuration for the custom Transformer. |
diffusion_pytorch_model.safetensors |
NegWAM Transformer weights. |
navhard_result.csv |
NAVSIM v2 navhard two-stage evaluation results and summary rows. |
navtest_result.csv |
NAVSIM v2 navtest evaluation results and the overall summary row. |
Keep config.json and diffusion_pytorch_model.safetensors in the same directory. The evaluation configuration's checkpoint_path must point to that directory.
| Benchmark | Split / protocol | EPDMS ↑ | Result file |
|---|---|---|---|
| NAVSIM v2 | navhard, two-stage | 40.4 | navhard_result.csv |
| NAVSIM v2 | navtest | 93.3 | navtest_result.csv |
Scores are shown on a 0–100 scale and rounded to one decimal place. They come from the extended_pdm_score_combined summary row for navhard and the average_all_frames summary row for navtest. For navhard, use the combined summary score rather than averaging all rows in the CSV, which contains both evaluation stages and aggregate rows.
The paper also reports zero-shot closed-loop evaluation on HUGSIM. See the paper for the protocol and results, and the GitHub release roadmap for code availability.
This release uses the Apache License 2.0.
If you use NegWAM in your research, please cite:
@misc{zhang2026negwam,
  title = {Reinforcing End-to-End Autonomous Driving Safety via Negative-Aware Planning in a Unified World-Action Model},
  author = {Zihao Zhang and Xinyu Zhang and Bing Zeng and Xingyu Chen and Zhenning Li and Bin Yu and Ziyuan Pu},
  year = {2026},
  eprint = {2611.08111},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2611.08111}
}