

DeepSignal-S1
One system, from visual traffic observations to signal decisions.
GitHub · Scene Dataset · Reproduction · Demo Video · 简体中文
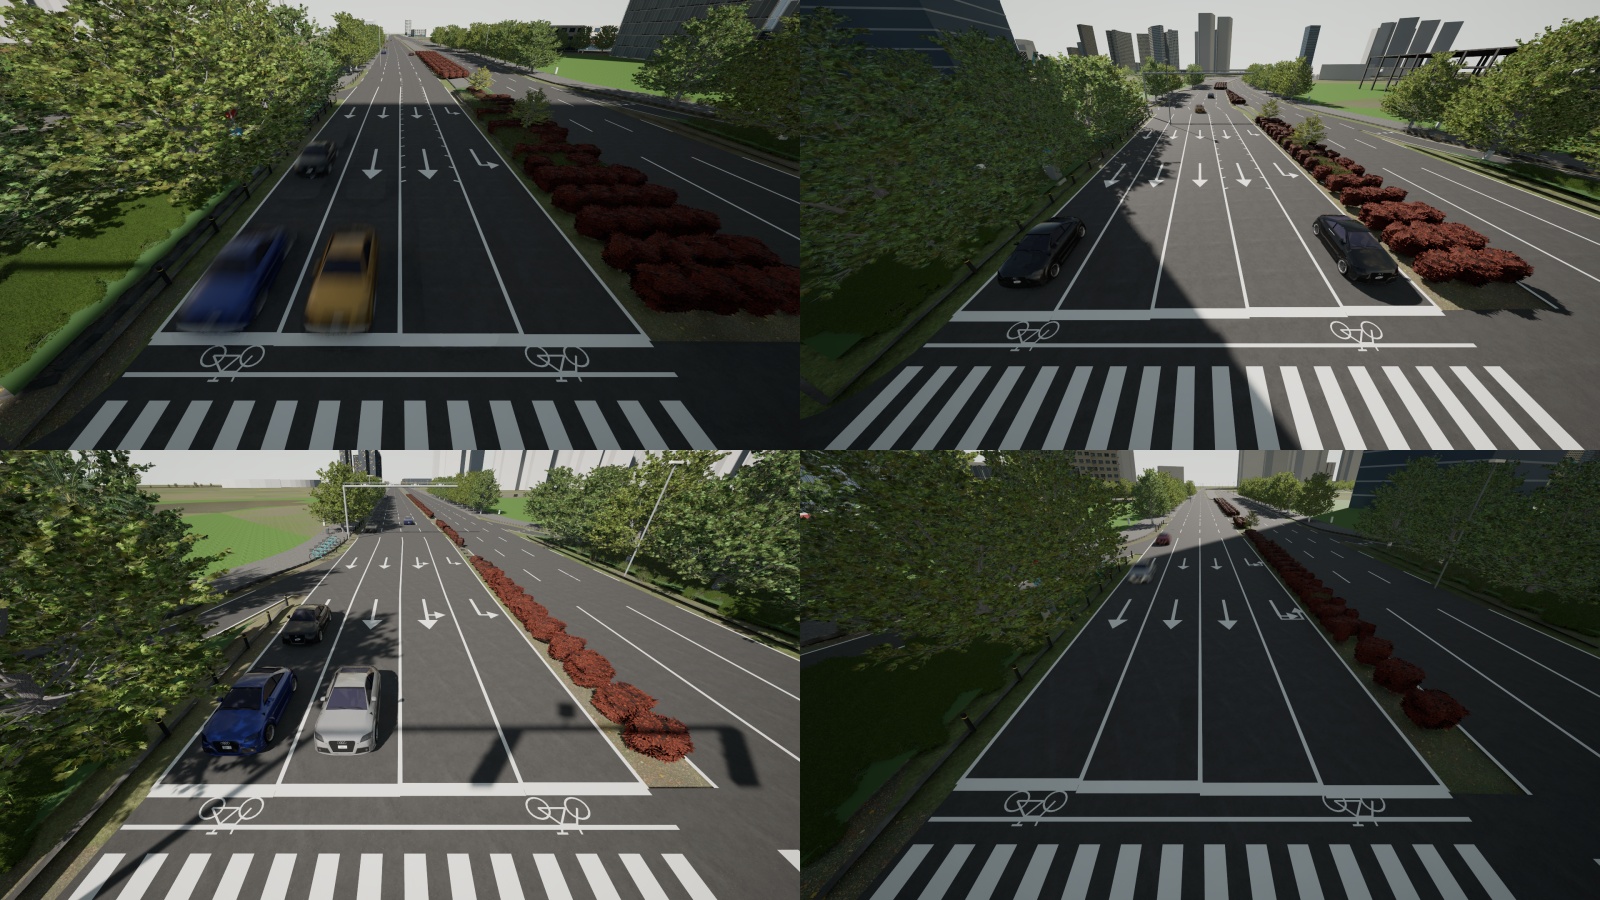
DeepSignal-S1 is a vision-first System One controller for traffic signals. S1 means one system: visual traffic understanding and signal-action selection are integrated into one multimodal decision interface. In a Jev-style, decision-first formulation, camera observations and current signal context directly produce a permitted control action rather than a conversational response. YOLO+MP is an independent baseline, not a component of the S1 controller.
This Release
- Repository: AIMS2025/DeepSignal-S1
- Model version:
DeepSignal-S1-1.0-candidate - Files: the complete current checkpoint and its standalone inference runtime.
- Test code: AIMS-Laboratory/DeepSignal-S1.
- Evaluation environment: Nansha, UE5/CARLA 0.10.0 and SUMO 1.18.0.
Only this current checkpoint is distributed in this repository. Historical Town10HD measurements in the test repository used a different checkpoint/runtime and must not be attributed to this model. The same-current-checkpoint supplementary evaluations are ongoing and are not included below.
Completed Nansha Measurements
The finite-horizon suite covers nine intersections, eight demand regimes and traffic seed 97001. Lower capped journey metrics are better.
| Camera Condition | Successful / Planned Pairs | Baseline | Journey-Metric Reduction |
|---|---|---|---|
| Clean | 72 / 72 | Engineering fixed timing | 15.99% |
| Static camera offsets within +/-8 degrees | 72 / 72 | YOLO+MP | 1.12% |
| Defocus, sigma=2.5 | 65 / 72 | YOLO+MP | 25.69% |
Under clean images, the overall result is close to YOLO+MP; five of nine intersection aggregates differ by less than 5%. The metric is per-case mean journey time capped at H=1298 seconds, including unfinished journeys. The defocus improvement is over the 65 jointly successful pairs; six S1 failures and one YOLO+MP failure remain in the raw records.
The separate three-seed Nansha J02 demonstration measures complete mean journey time: 2.15% shorter than YOLO+MP under defocus, 2.36% for clean east-west-heavy demand and 2.06% for clean north-south-heavy demand. These complete-journey values are not pooled with the finite-horizon suite.
Raw Results · Exact Cases and Protocol · Complete-Journey Demonstrations
Download and Run
Downloads require an approved access request. Request access on this model page, then authenticate with your own Hugging Face account. Public GitHub access does not grant model access.
Use a Python 3.12 inference environment. The unquantized model requires an NVIDIA GPU; at least 24 GB VRAM is recommended for inference alone. Scene rendering needs additional GPU resources. Keep the Python 3.10 CARLA client in a separate environment.
python3.12 -m venv .venv-inference
source .venv-inference/bin/activate
pip install huggingface_hub
hf auth login
hf download AIMS2025/DeepSignal-S1 --local-dir ./DeepSignal-S1

pip install -r ./DeepSignal-S1/requirements.txt
git clone https://github.com/AIMS-Laboratory/DeepSignal-S1.git DeepSignal-S1-test
python DeepSignal-S1-test/scripts/serve_model.py \
  --model ./DeepSignal-S1 --port 18404 --device cuda:0
Download the complete folder, not only decision/. The server binds to localhost by default. GET /health reports the model version. POST /v1/decide consumes three chronological camera JPEG composites, static intersection context, the current signal state and legal actions; it returns a permitted choice. Simulator vehicle counts, future arrivals and recorded reference answers are not model inputs. Model download approval does not create a hosted API service.
The combined Nansha + Town10HD scene dataset publicly hosts DeepSignal-S1-Scenes-v2.tar.gz (27.60 GiB). Check the dataset card for upload readiness; no Google Drive download is required. It includes the two UE5 scenes and the historical Town CARLA 0.9.16 runtime, but no model weights. Scene access is separate from this model's approval process.
hf download AIMS2025/DeepSignal-S1-Scenes DeepSignal-S1-Scenes-v2.tar.gz \
  --repo-type dataset --local-dir ./downloads
Follow the GitHub reproduction guide for scene installation, matching runtimes, camera setup, traffic plans and baseline tests. Historical Town scores still require their separate archive checkpoint, which is not distributed here or in the scene dataset.
Scope and Notices
Results apply to the specified simulation conditions, not every intersection, camera perturbation or real-world deployment. A complete fresh-download closed-loop replay has not yet been certified; different hardware, drivers or dependencies may change numerical results. Required third-party terms are retained in engine/LICENSE and engine/NOTICE.
简体中文
S1 代表 one system:从视觉交通状态到信号决策的一体化系统。 DeepSignal-S1 采用面向决策的 System One / Jev-style 接口,直接根据摄像头画面与当前信号上下文选择合法控制动作,不生成对话式回答,也不依赖单独的 YOLO 感知环节。YOLO+MP 仅作为独立对照。
GitHub 主页 · 场景数据集 · 复现说明 · 展示视频
本次模型
本仓库只提供当前这一份权重及其完整推理文件,版本为 DeepSignal-S1-1.0-candidate,已完成成绩对应南沙 UE5/CARLA 0.10.0、SUMO 1.18.0 环境。GitHub 中的历史 Town10HD 成绩来自不同版本的权重与环境,不能归给本仓库这份模型。后台正在补充同一当前权重的测试,未把未完成结果写入成绩表。
已完成效果
| 画面条件 | 成功配对 / 计划 | 对照 | 截断行程指标改善 |
|---|---|---|---|
| 清晰 | 72 / 72 | 工程固定配时 | 15.99% |
| 整回合固定的相机角度偏移,范围 ±8° | 72 / 72 | YOLO+MP | 1.12% |
| 失焦,sigma=2.5 | 65 / 72 | YOLO+MP | 25.69% |
测试覆盖南沙九路口、八类需求和种子 97001。清晰条件下与 YOLO+MP 整体接近,**9 个路口中 5 个的汇总差异不到 5%**。这里使用 H=1298 秒的截断平均行程,未完成车辆仍计入,不是所有车辆完成后的平均行程。失焦改善来自双方均成功的 65 对;模型 6 个失败、YOLO+MP 1 个失败的记录均保留。
另有南沙 J02 三个种子的完整行程展示:失焦时相对 YOLO+MP 改善 2.15%,清晰东西向、南北向需求分别改善 2.36% 和 2.06%。两套指标分别统计,不混算。
下载与测试
模型采用申请审批制,获批后使用自己的 HF 账号下载完整目录。按上方命令建立 Python 3.12 推理环境,安装本目录的 requirements.txt,通过 GitHub 测试仓库的 scripts/serve_model.py 启动本地服务。仅推理建议至少 24 GB 显存,三维场景渲染需要额外资源;CARLA 客户端另用 Python 3.10 环境。
HF 场景数据集公开托管南沙与 Town10HD 的统一场景包 DeepSignal-S1-Scenes-v2.tar.gz(27.60 GiB),无需 Google Drive,上传就绪状态见数据集卡片。可用上方 hf download 命令下载。包内包含两套 UE5 场景与历史 Town 的 CARLA 0.9.16 运行环境,不含任何模型权重;下载场景不需要先获得模型权限,也不代表获得了历史 Town 权重。
GitHub 仓库提供场景构建、固定车流、基线与测试代码。复现说明列出版本、安装步骤与指标定义。模型根据三帧画面和当前信号上下文决策,不接收仿真车辆真值、未来到达计划或历史参考答案。获批下载模型不等于开通了远程托管 API。
结果只适用于明确列出的仿真条件,不保证任意路口、扰动或真实道路都取得同样改善。从公开下载开始的完整闭环复跑尚未验收,不声称不同硬件、驱动或依赖下逐位一致。必要第三方条款保留在 engine/LICENSE 与 engine/NOTICE。
联系 / Contact: dalei@scu.edu.cn